SmartB
Replace weight sensor
|
In this document you will find a description how to replace the weight sensor in the Smartb
|
You will need:
|
Before replacing disconnect device from the power supply!
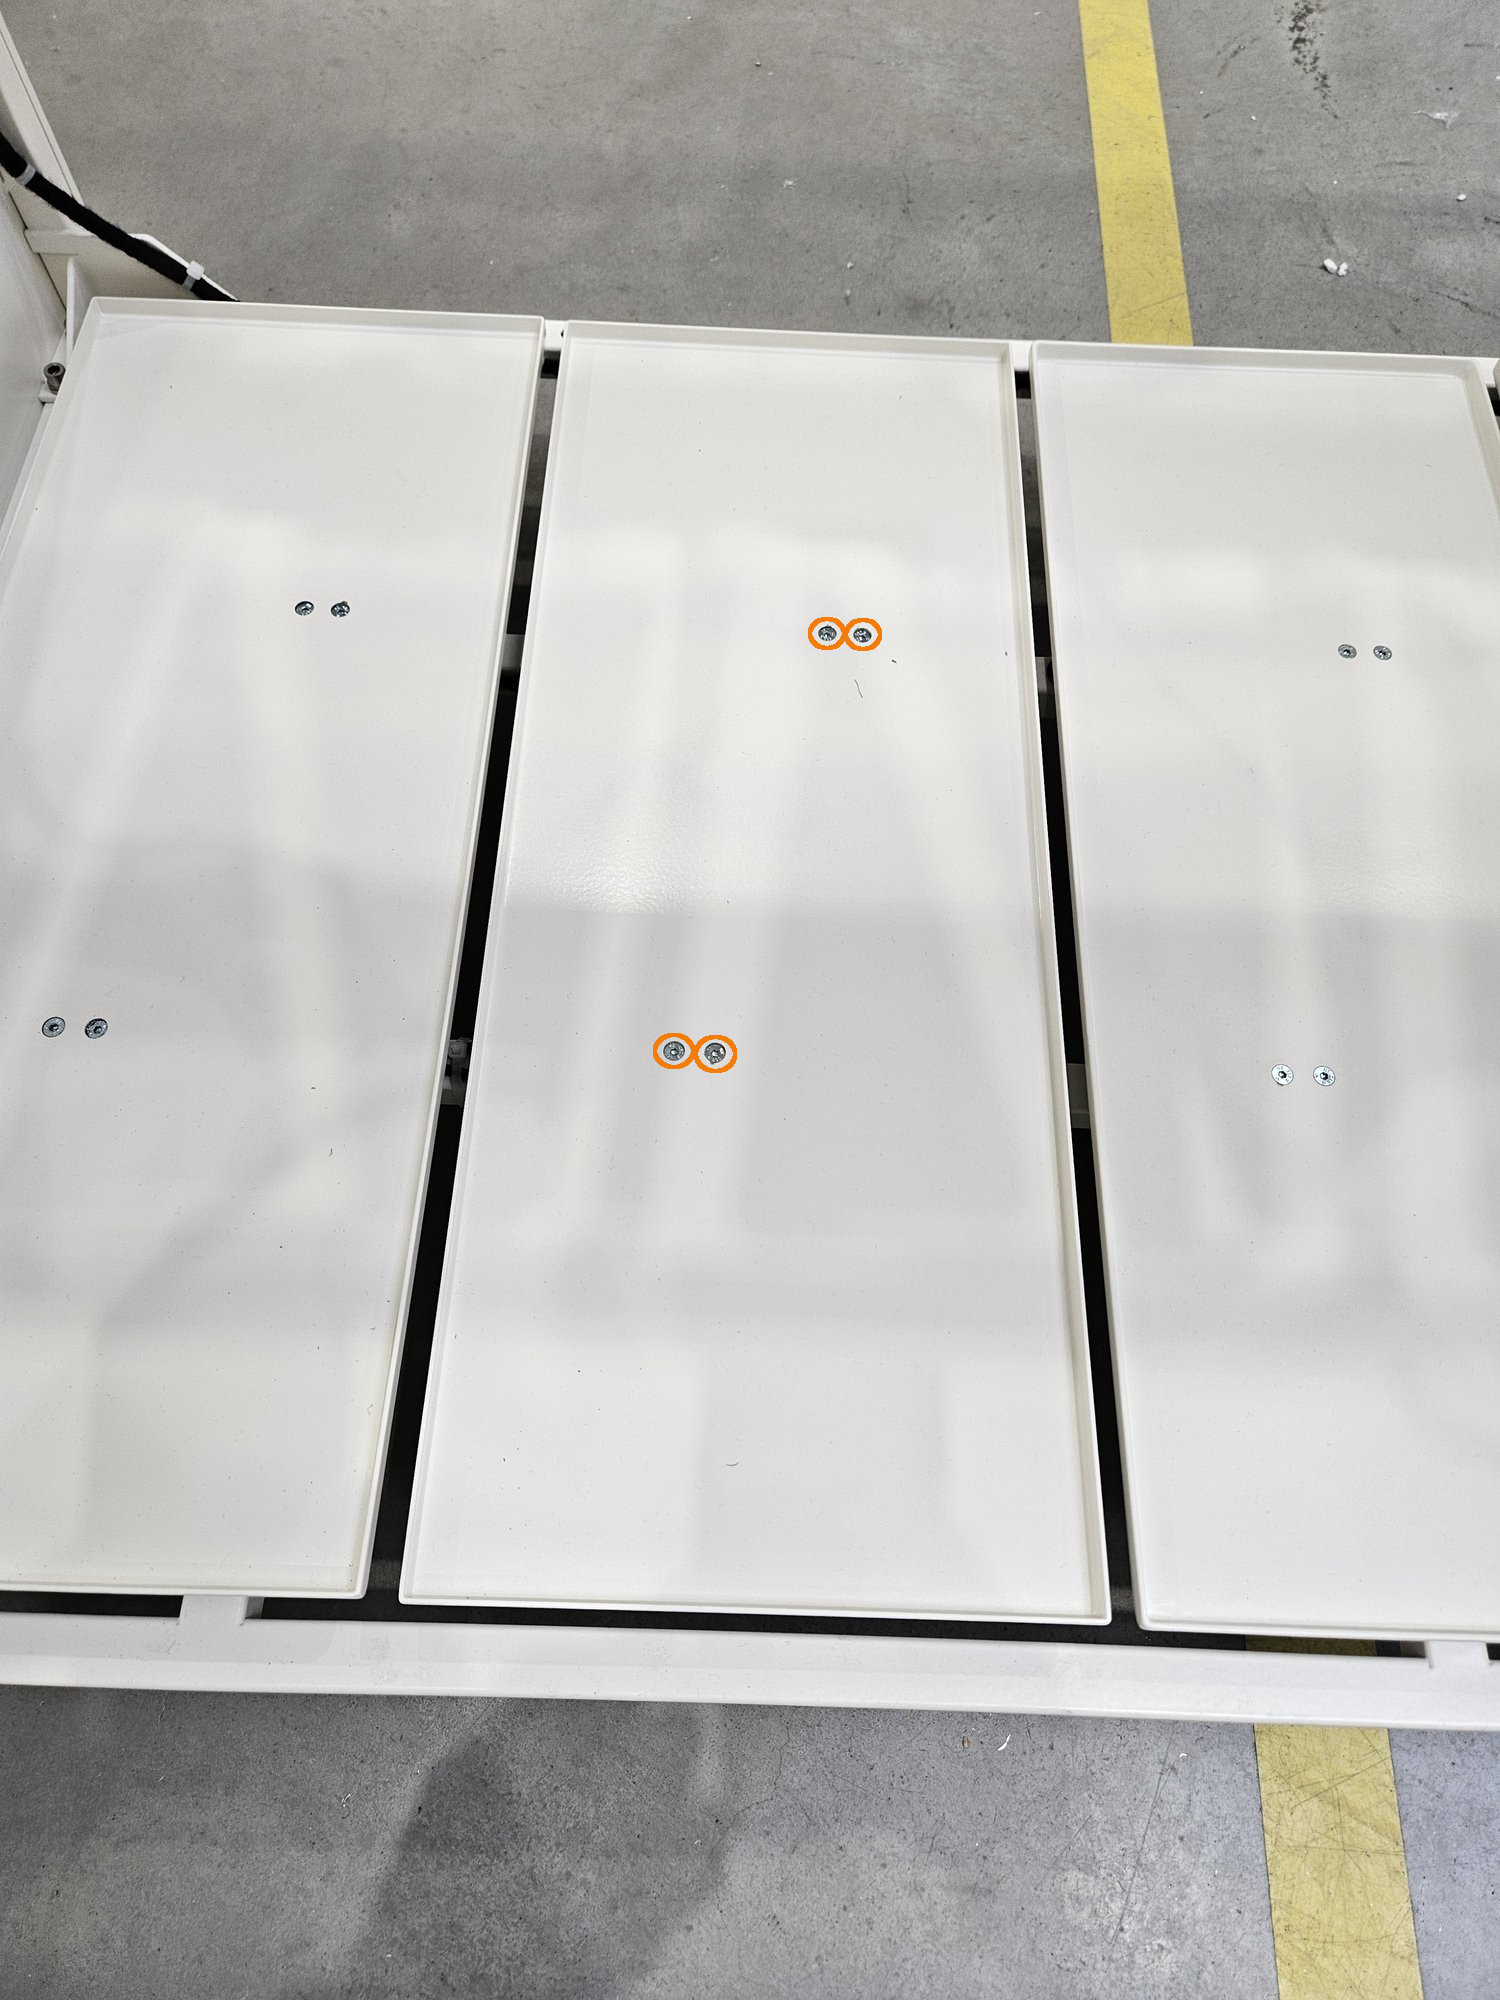
Step 1 Unscrew the top floor
|
 |
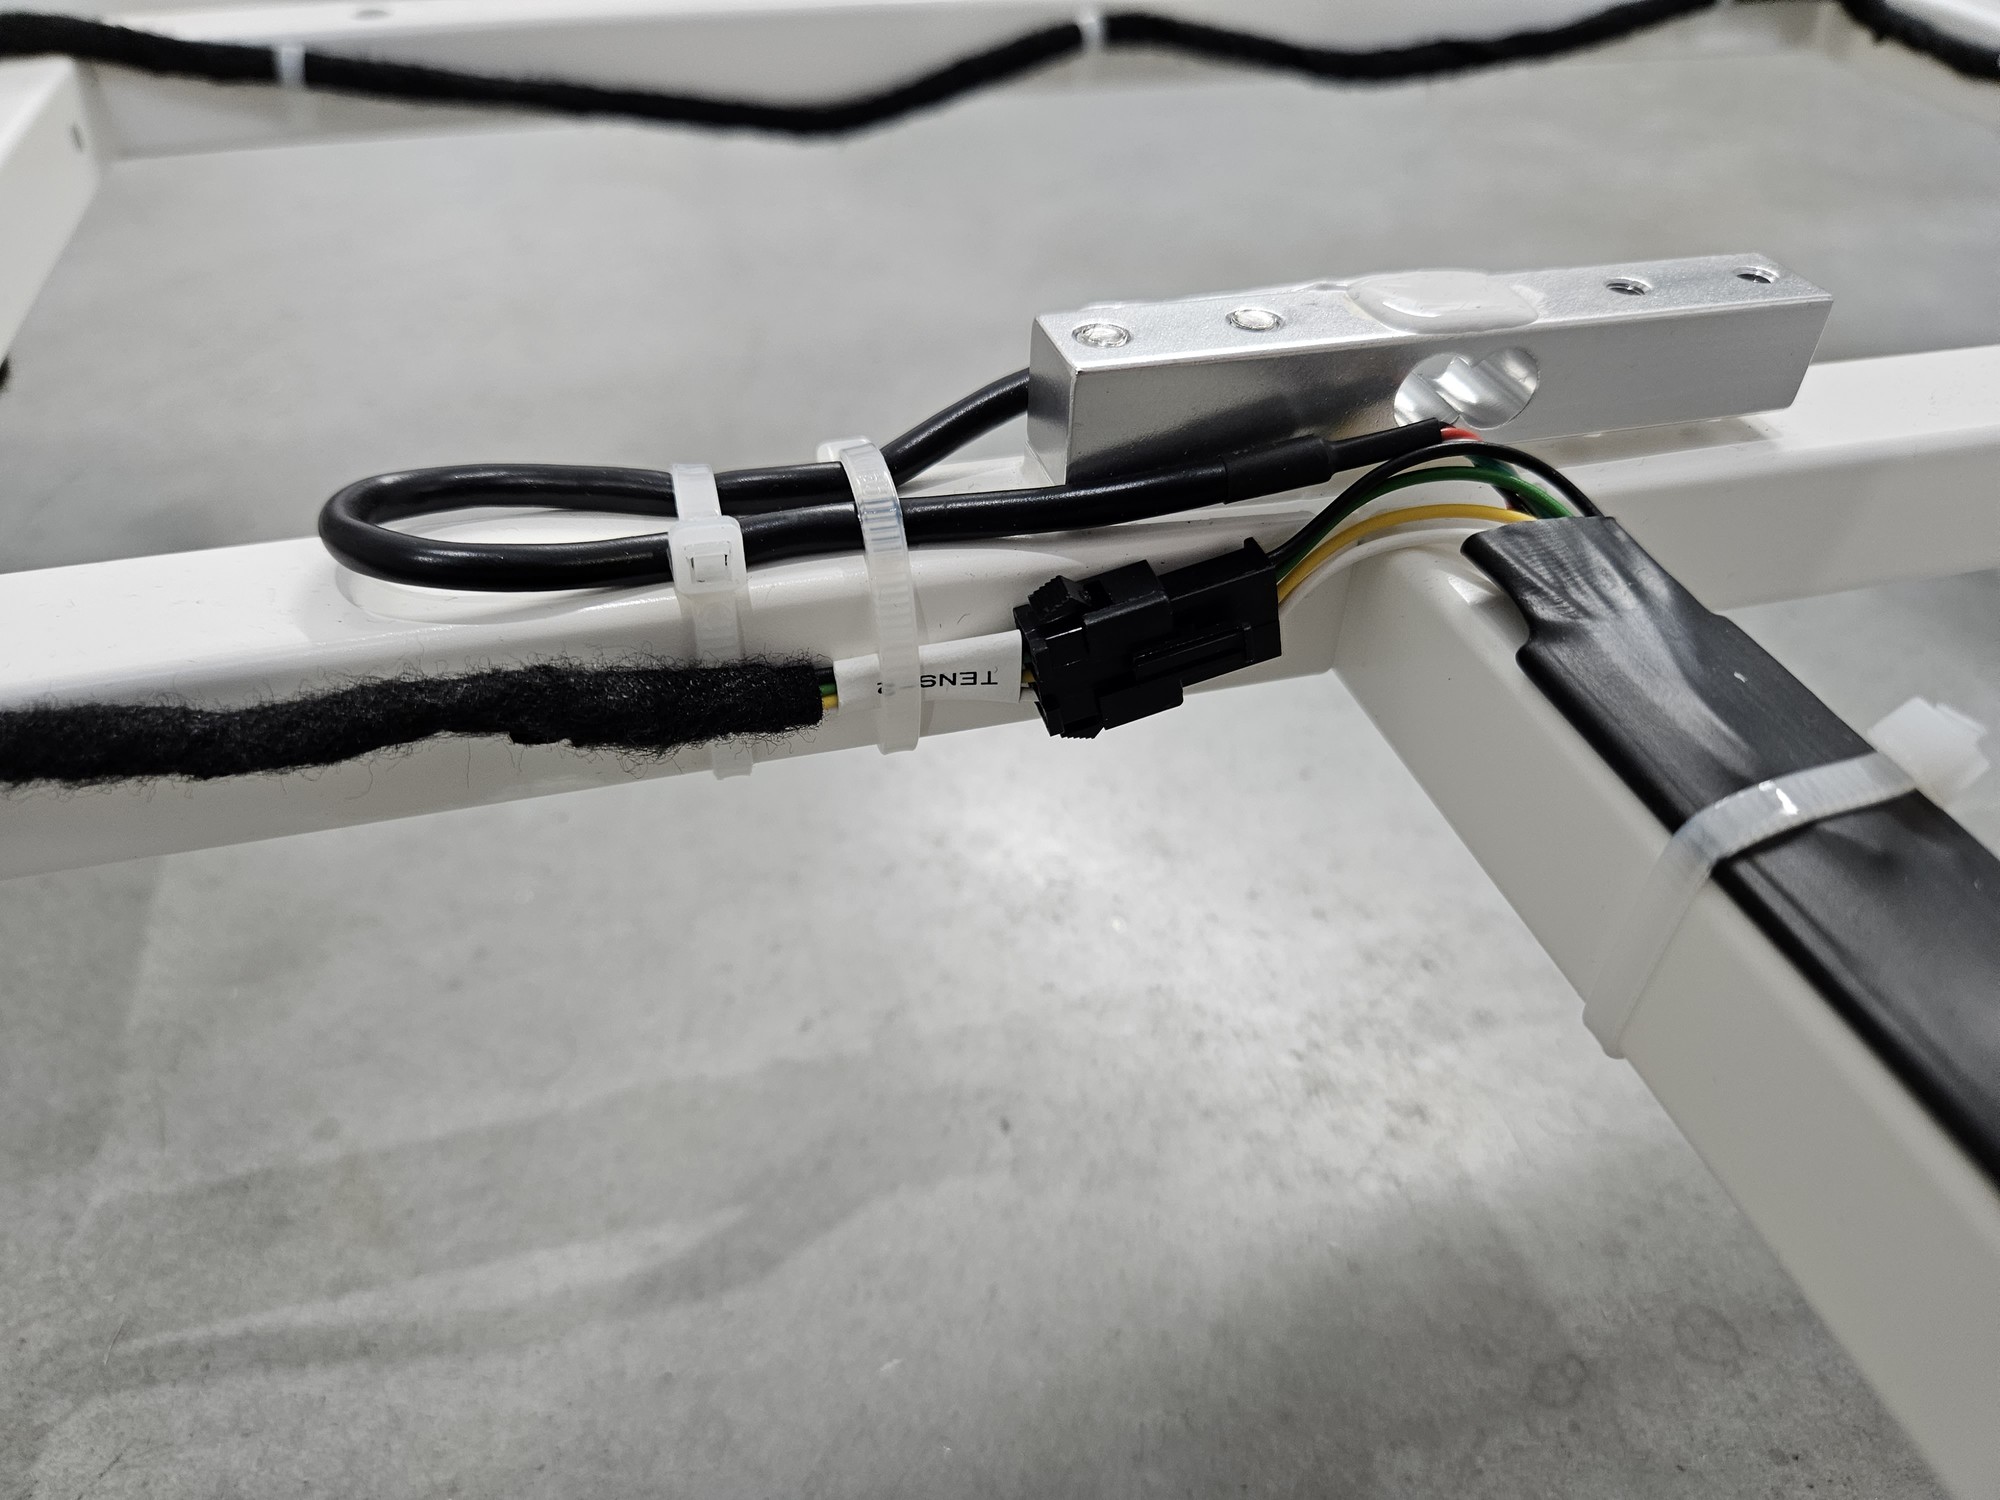
Step 2 Unplug the sensor
|
 |
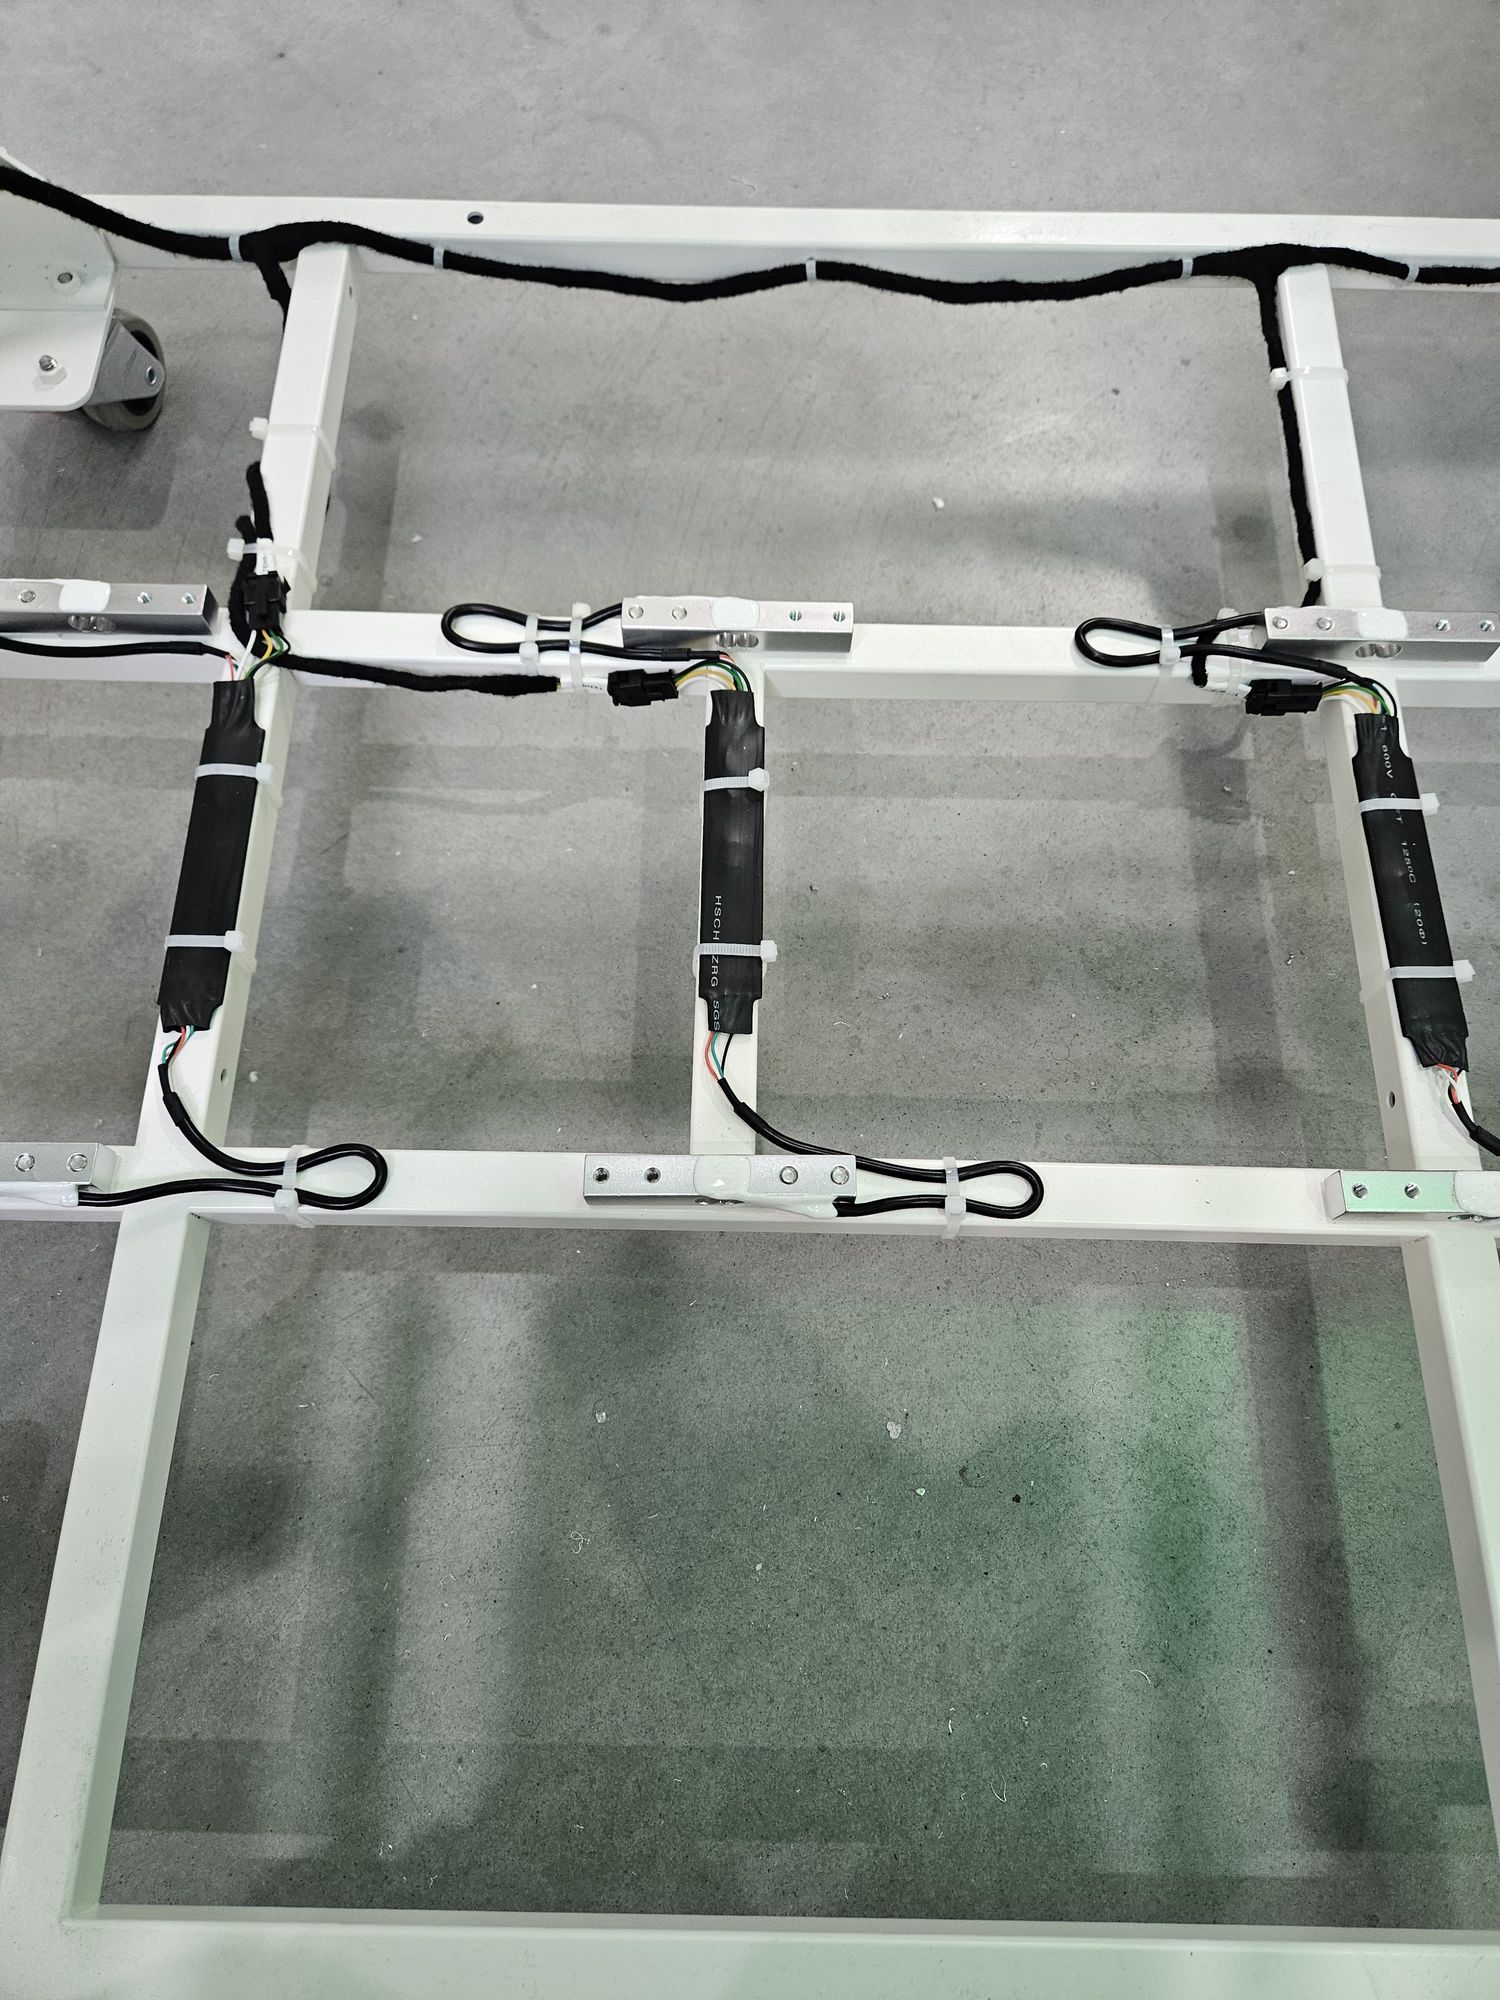
Step 3 Remove zippers
 |
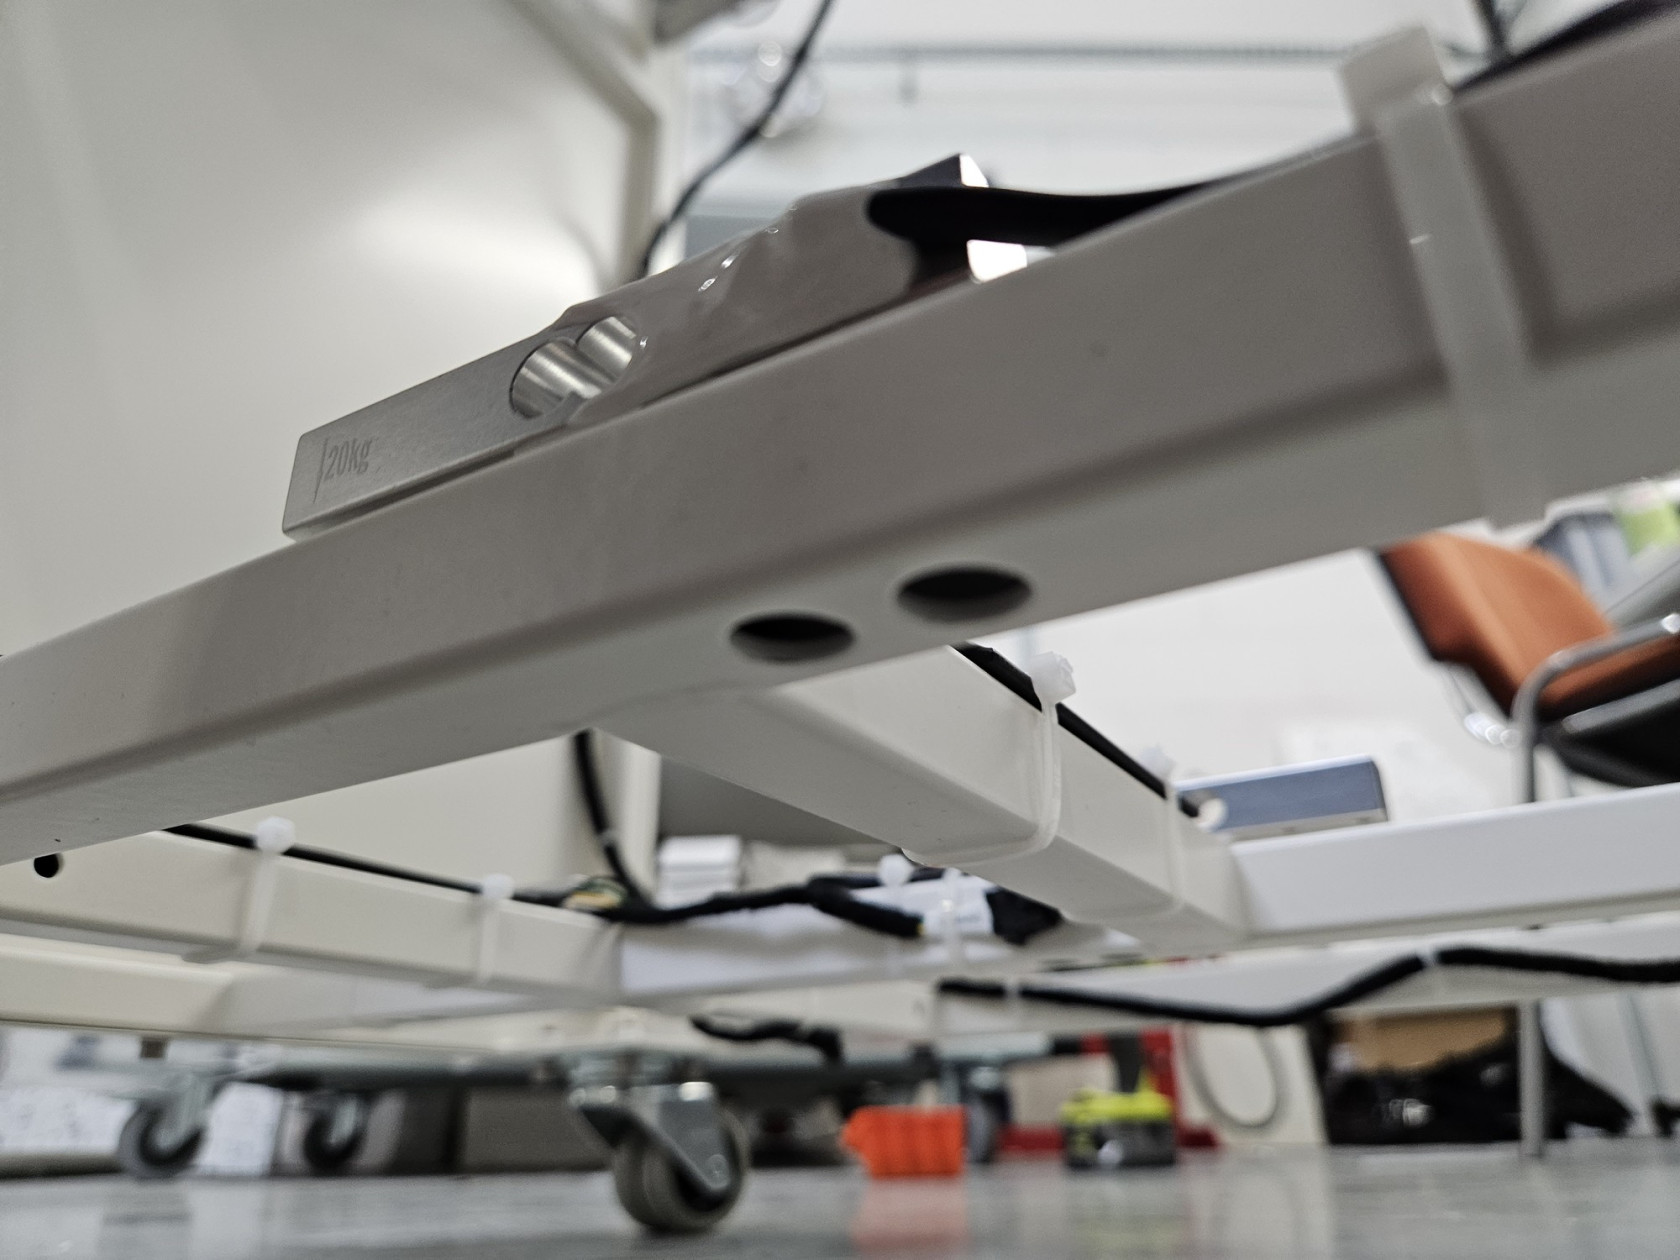
Step 4 Unscrew sensor form frame
|
|
|
|
|
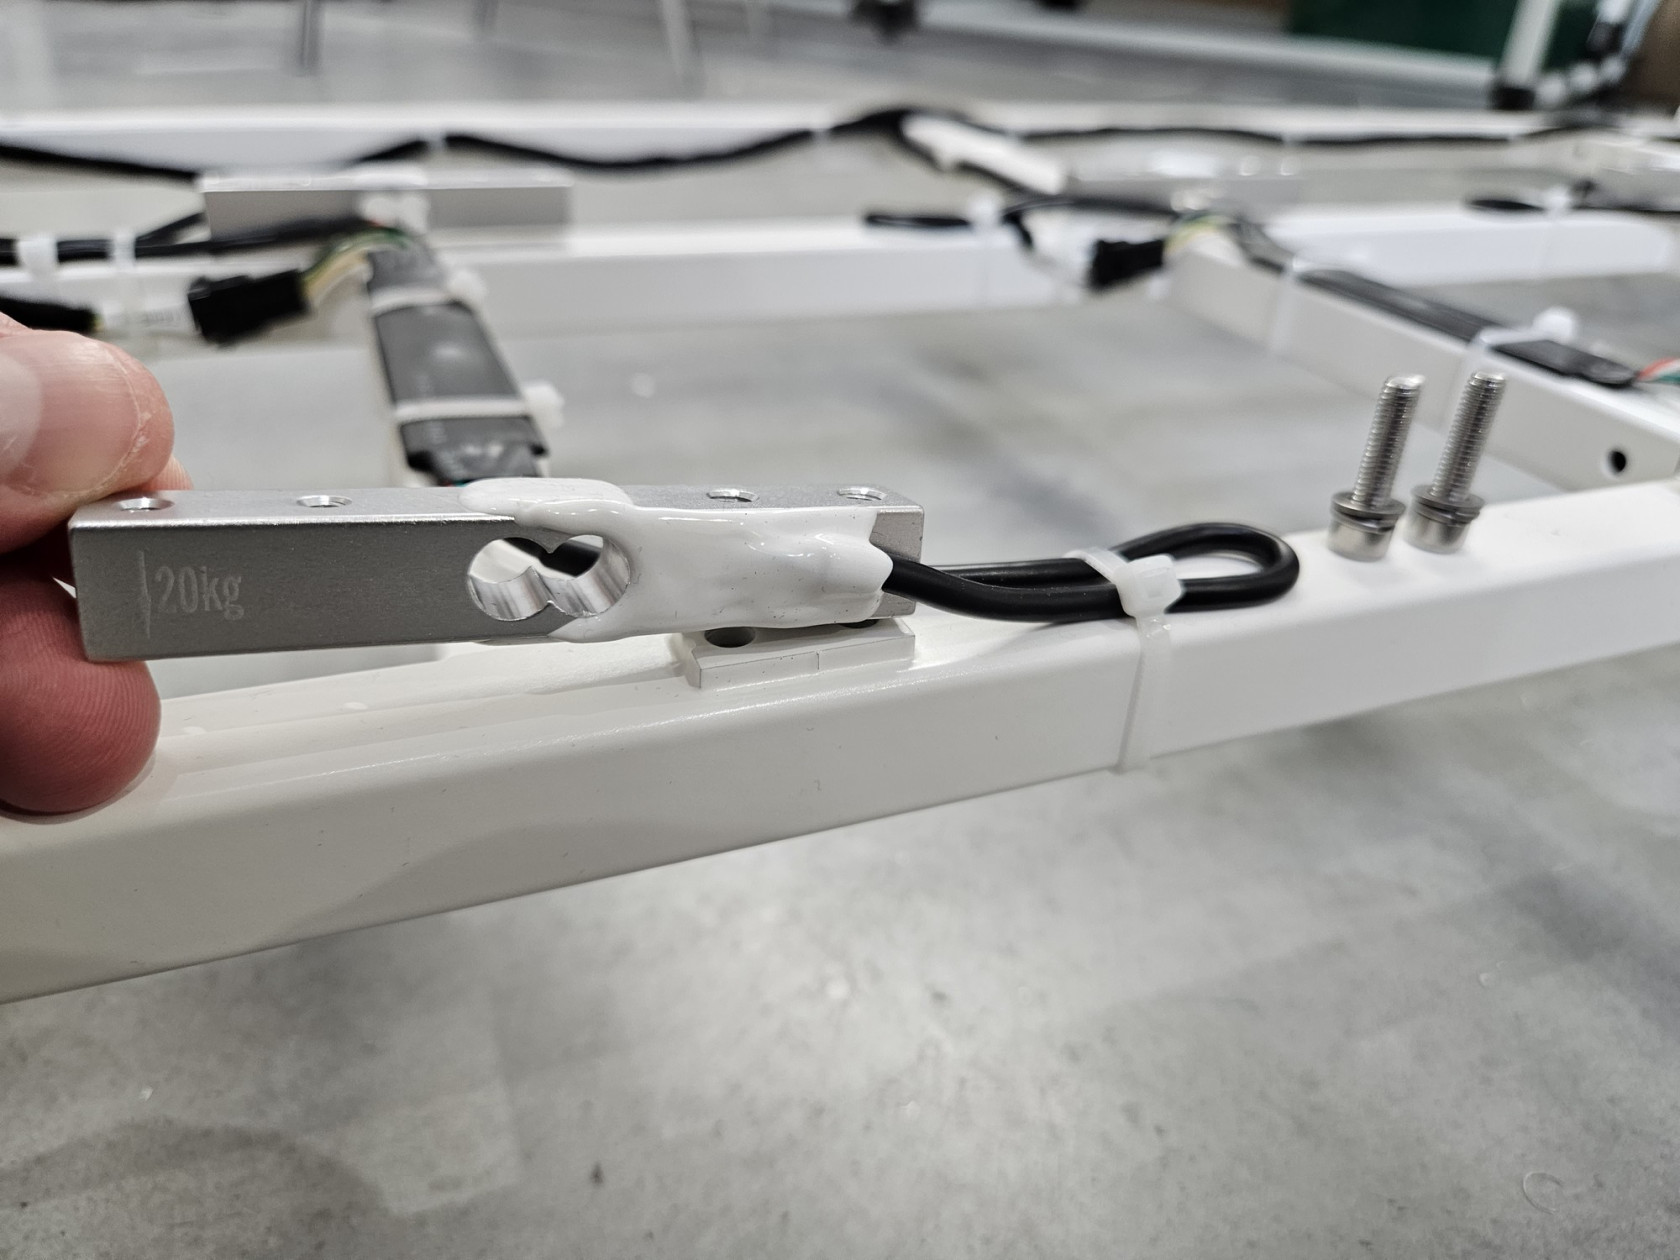
Step 5 Set new sensor
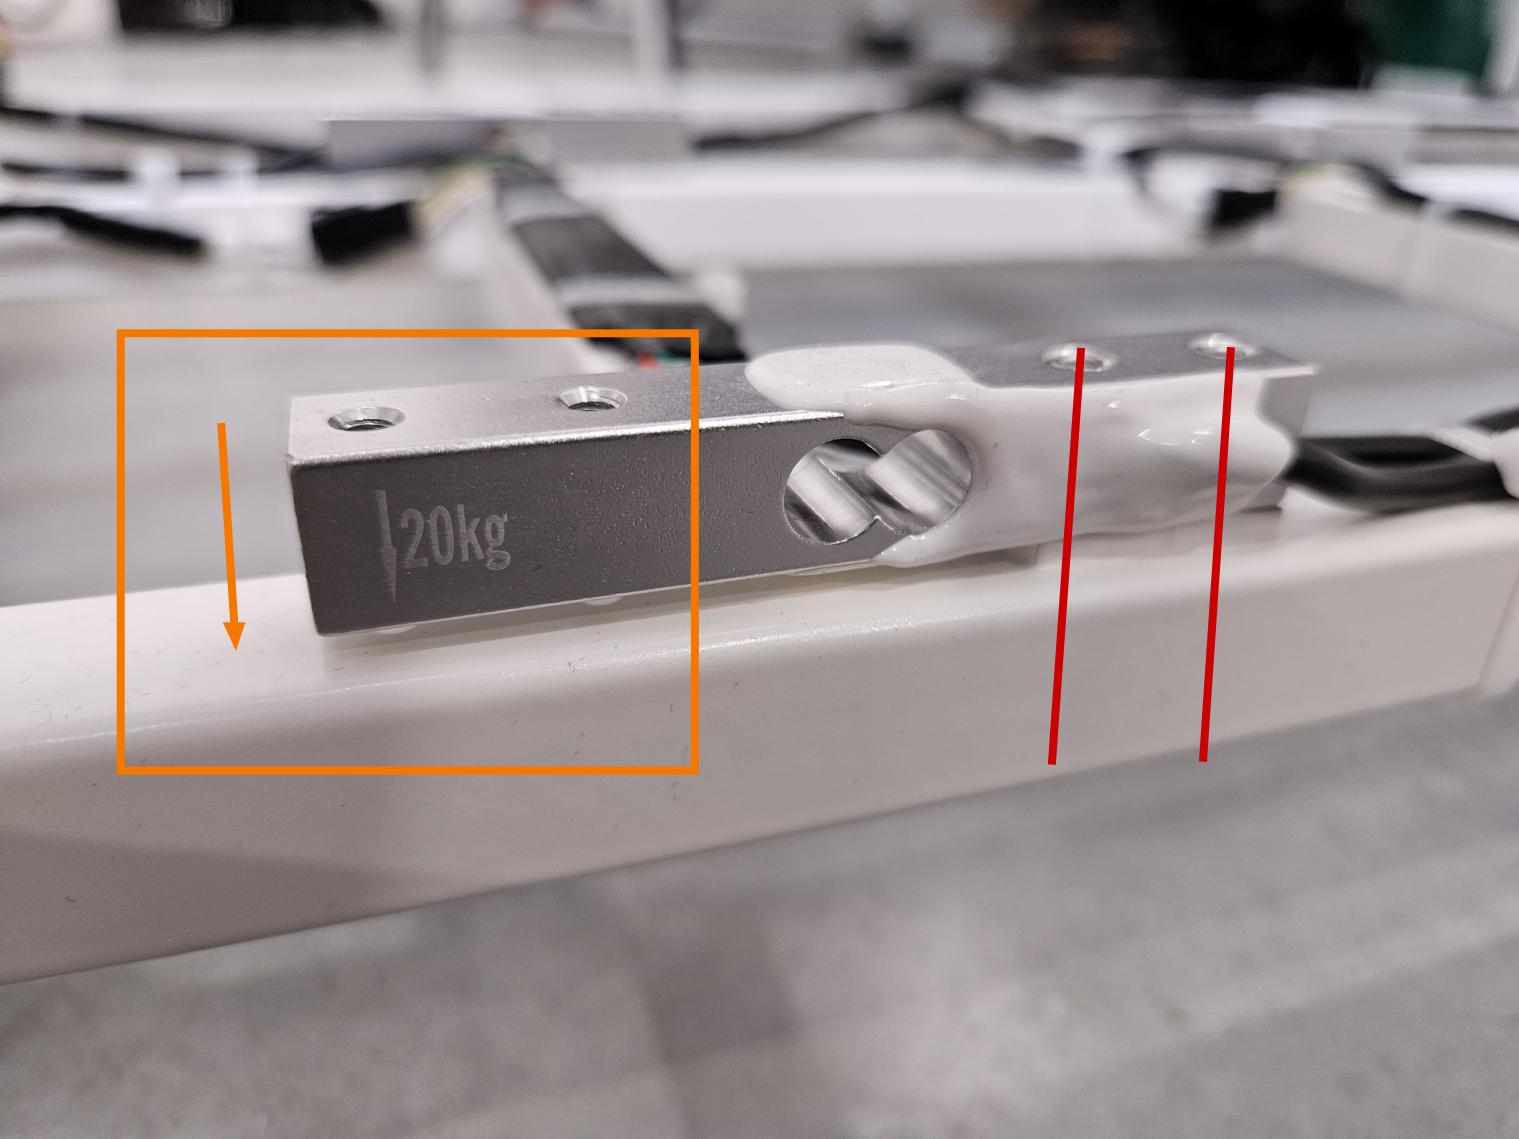
Pay special attention to the direction! The beam has an arrow drawn on it. This arrow should point down and be on the opposite side of the mounting screws to the frame! (see photo below)
On the front of the device, the arrow should be on the left and on the back on the right.
|
 |
Step 6 Secure cable and PCB with zippers
|
|
|
Step 7 Plug in a new sensor
|
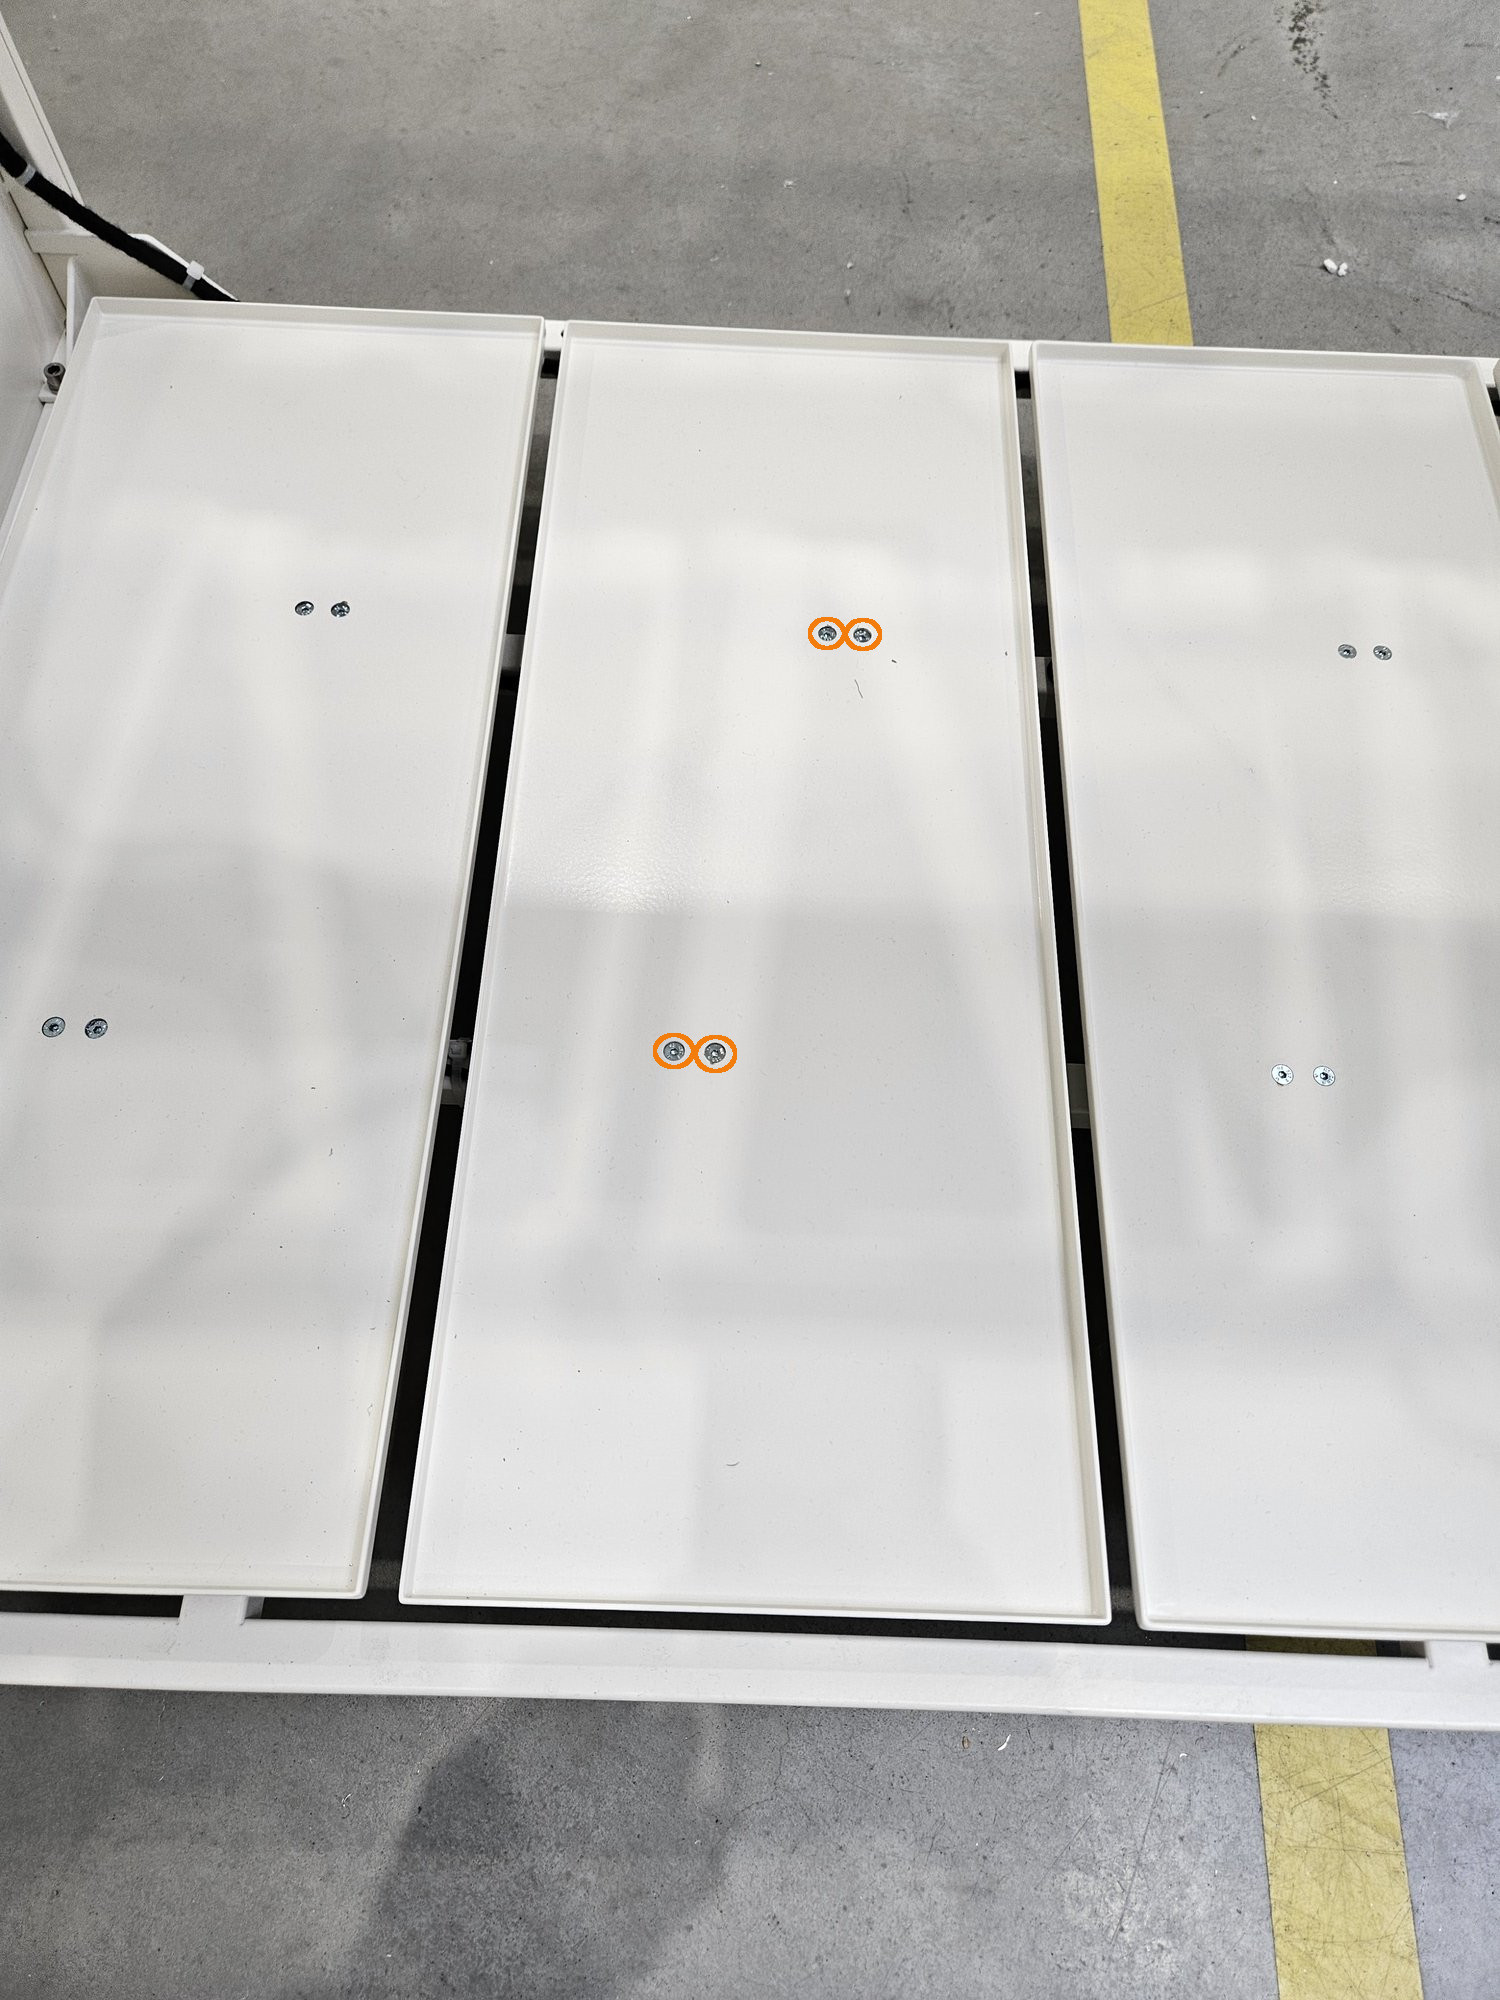
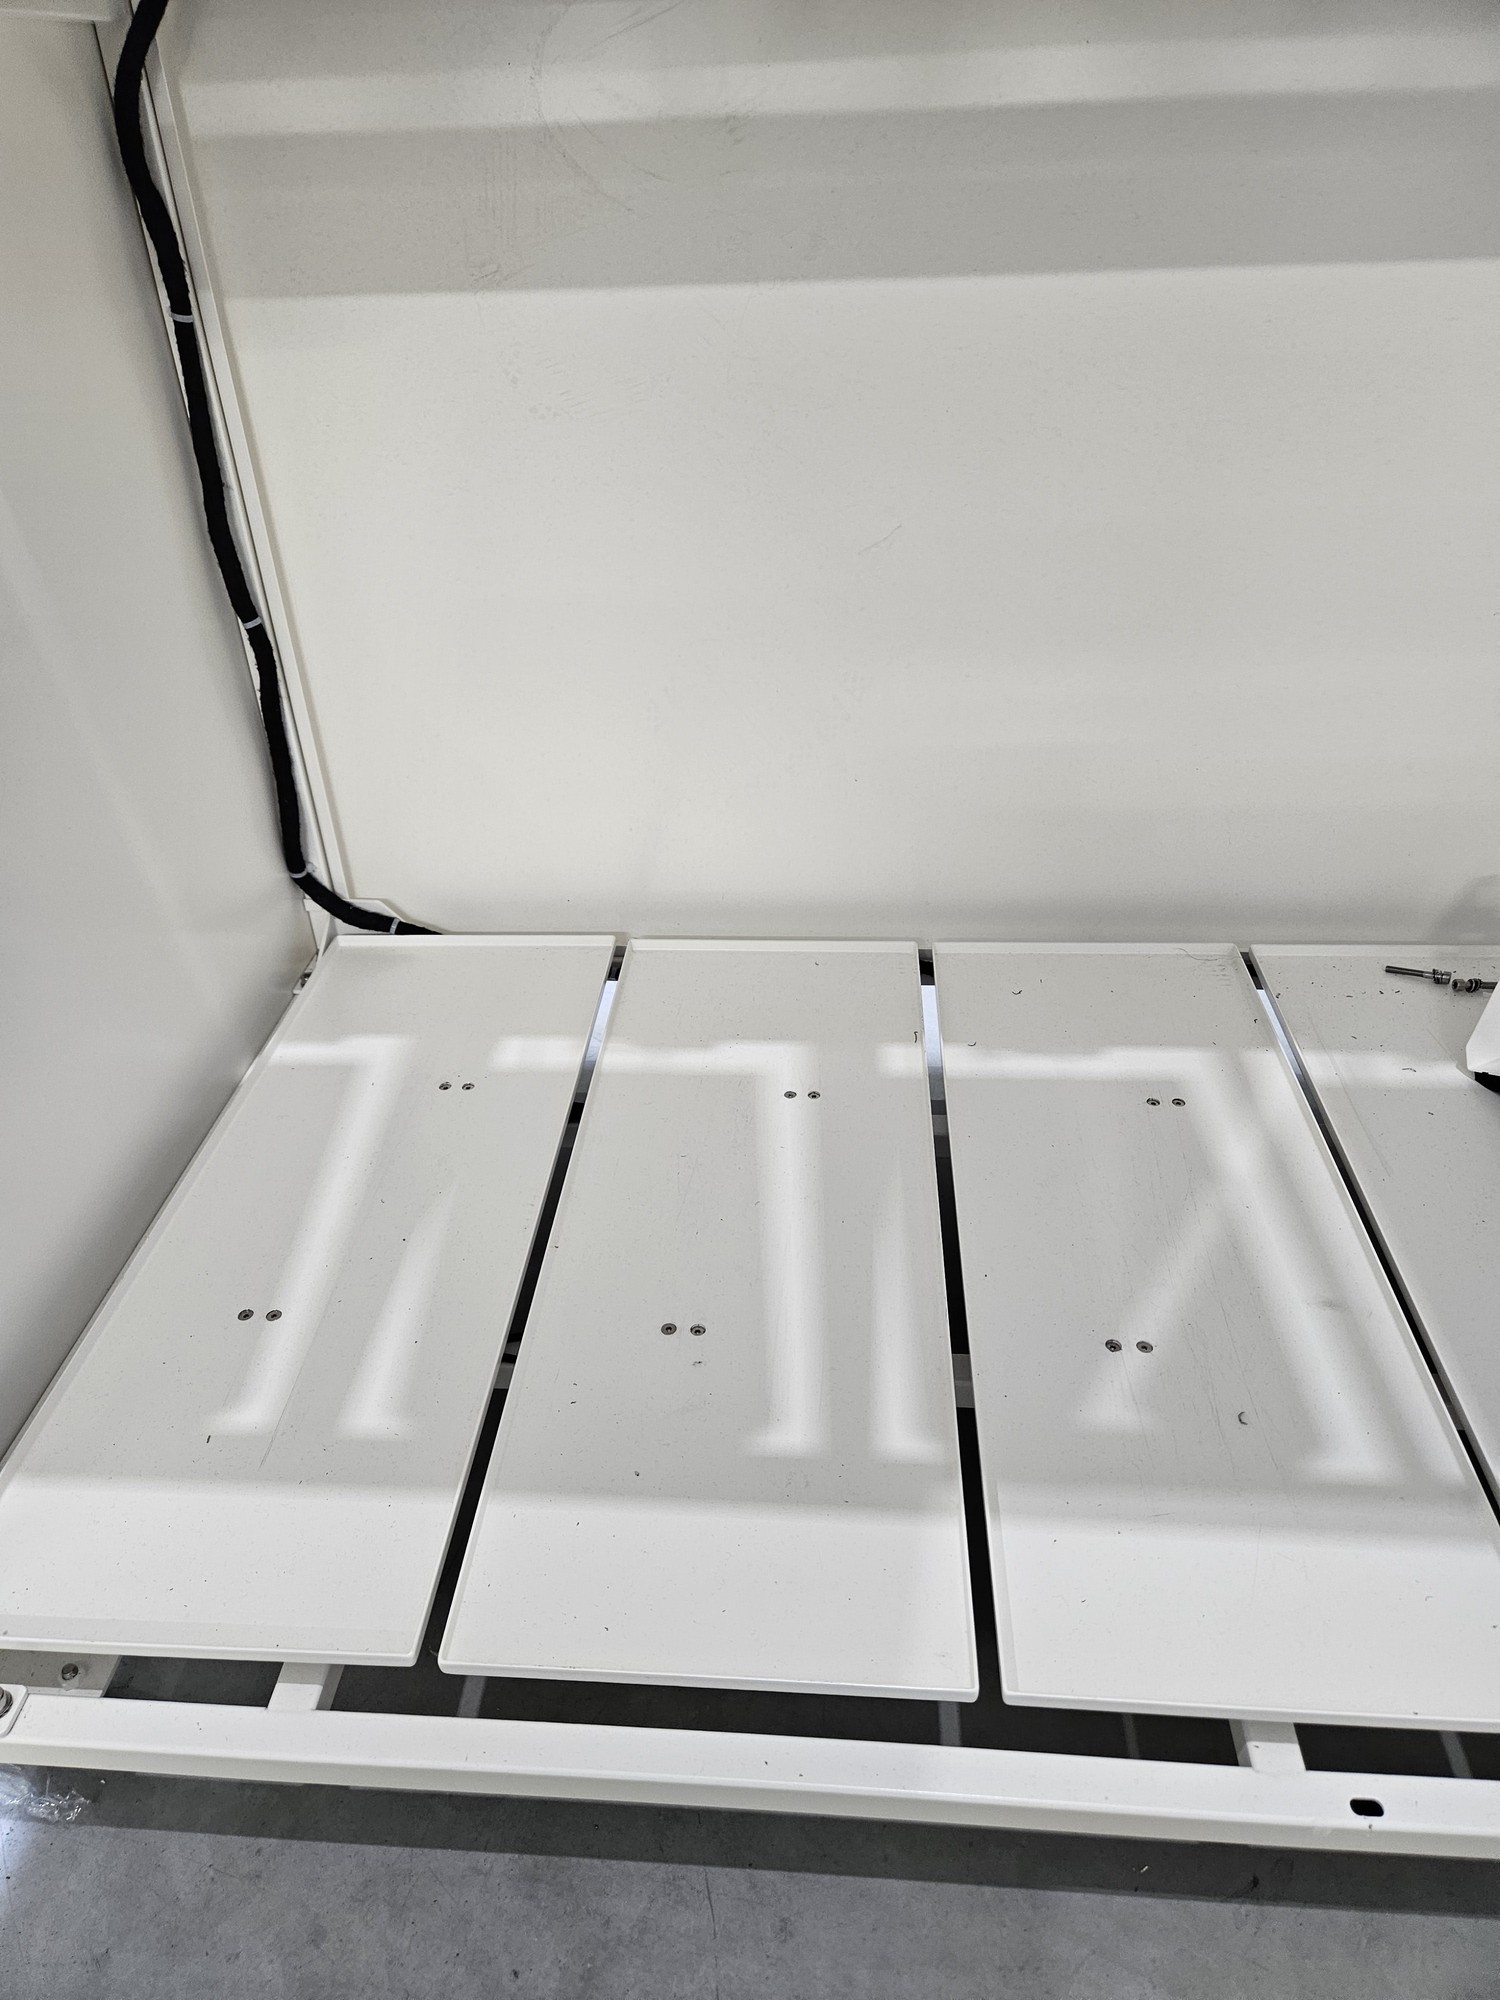
Step 8 Screw flor again
The floor is not symmetrical! Orient it similarly to the others!
 |
Step 9 Wieght calibration
Full calibration is required after load cell replacement. THIS IS A DIFFERENT CALIBRATION THAN ZERO CALIBRATION FROM THE MENU. Right now there is no possible full calibration from user menu.
Calibration consists of 4 stages
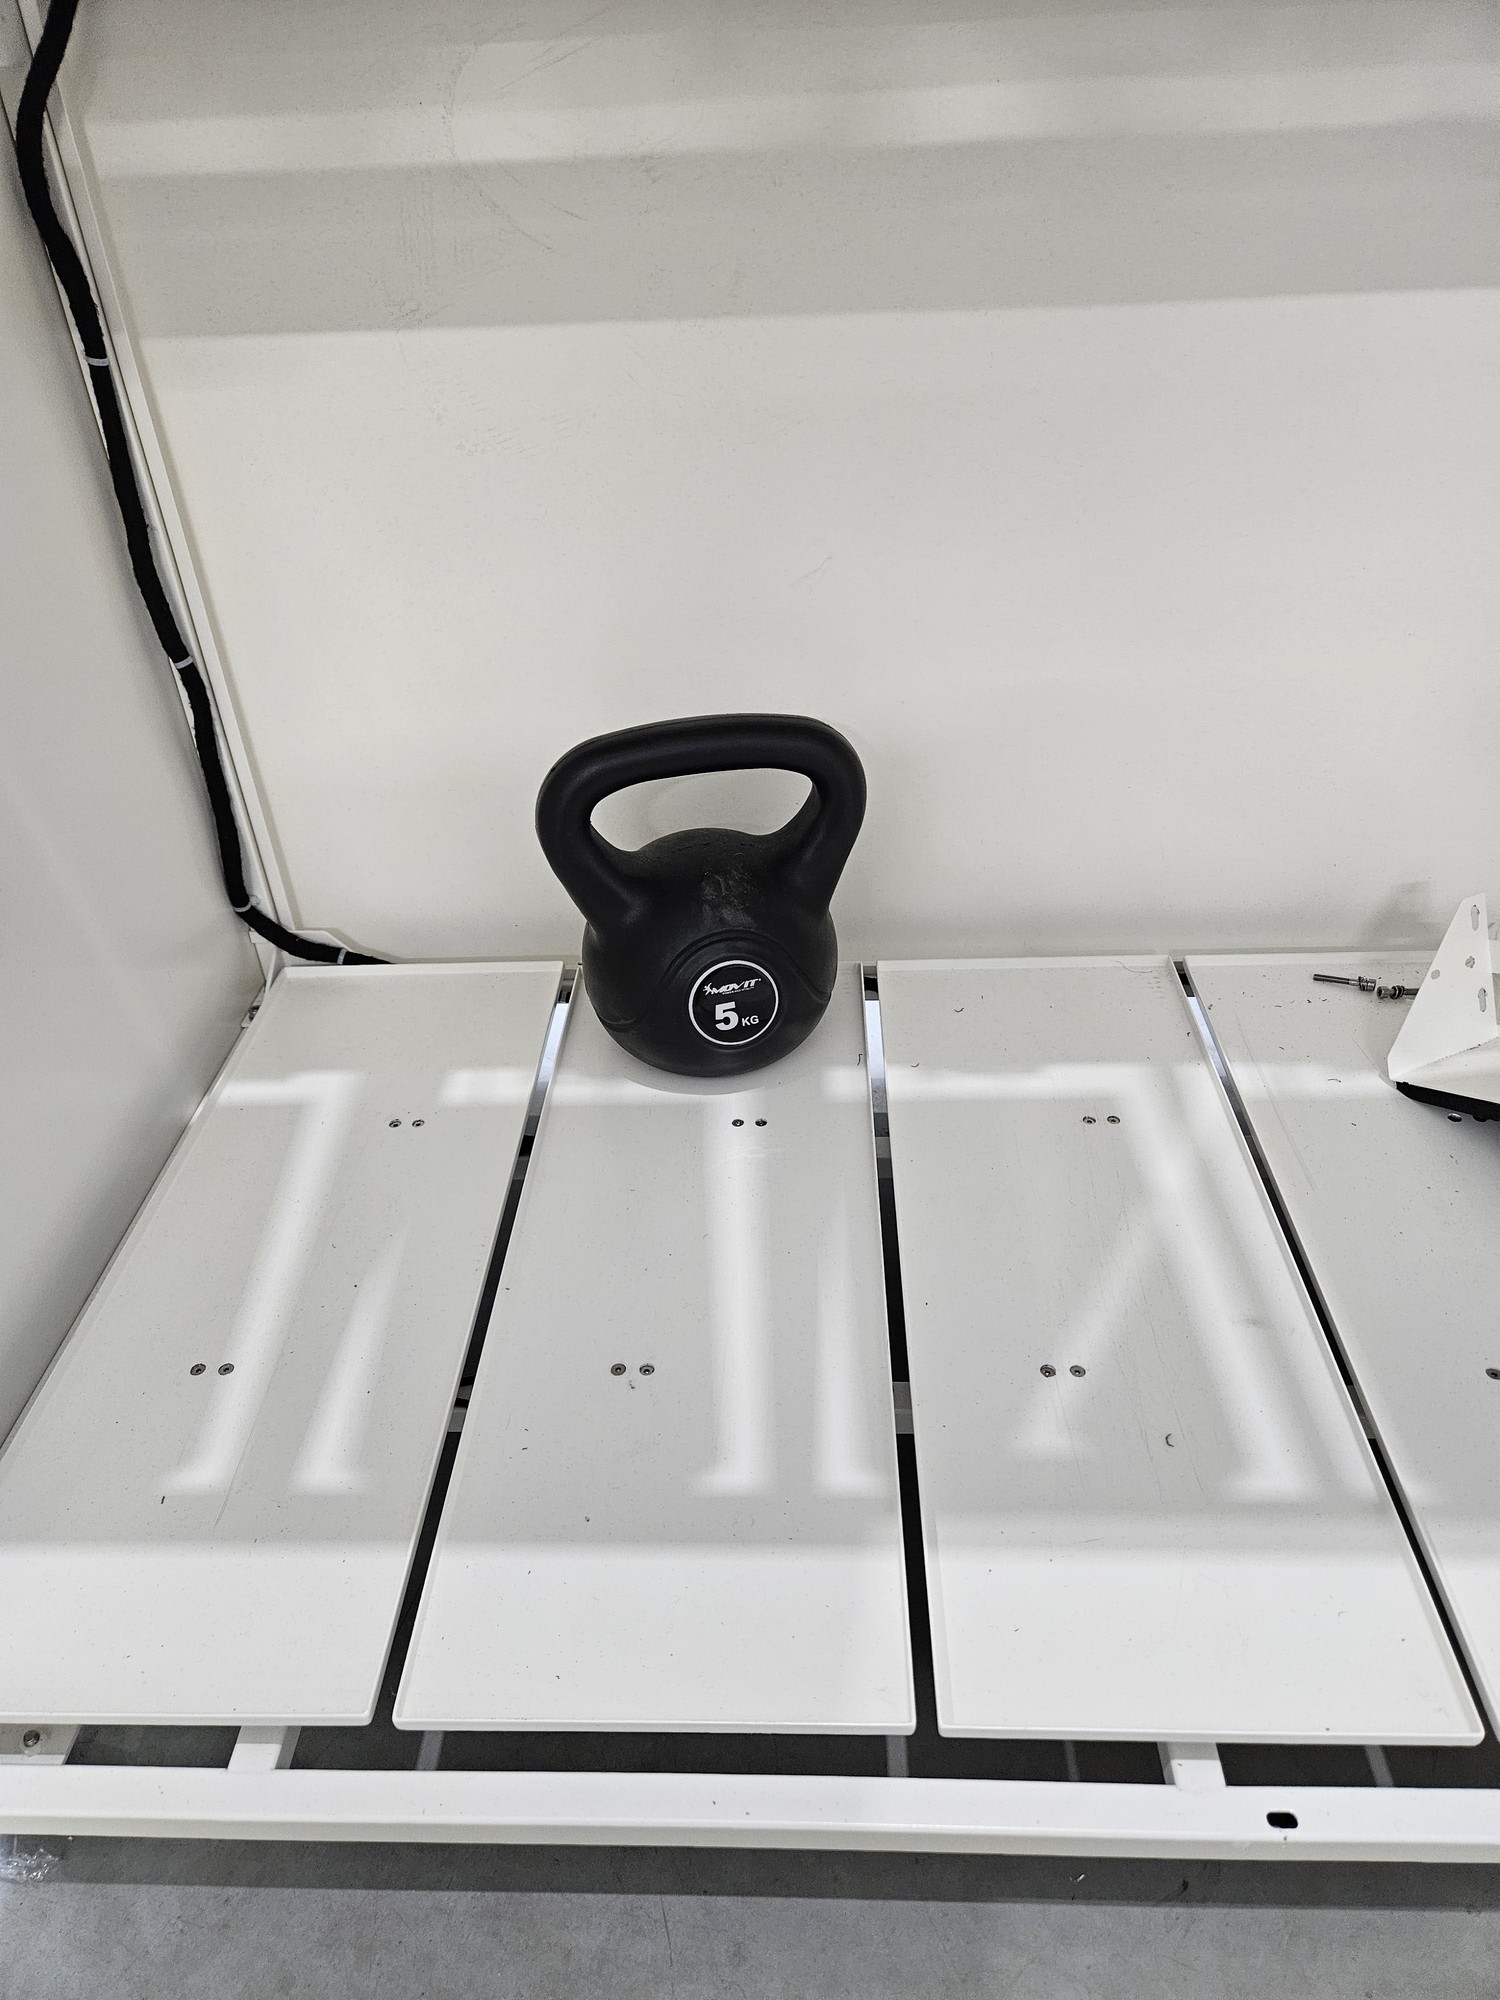
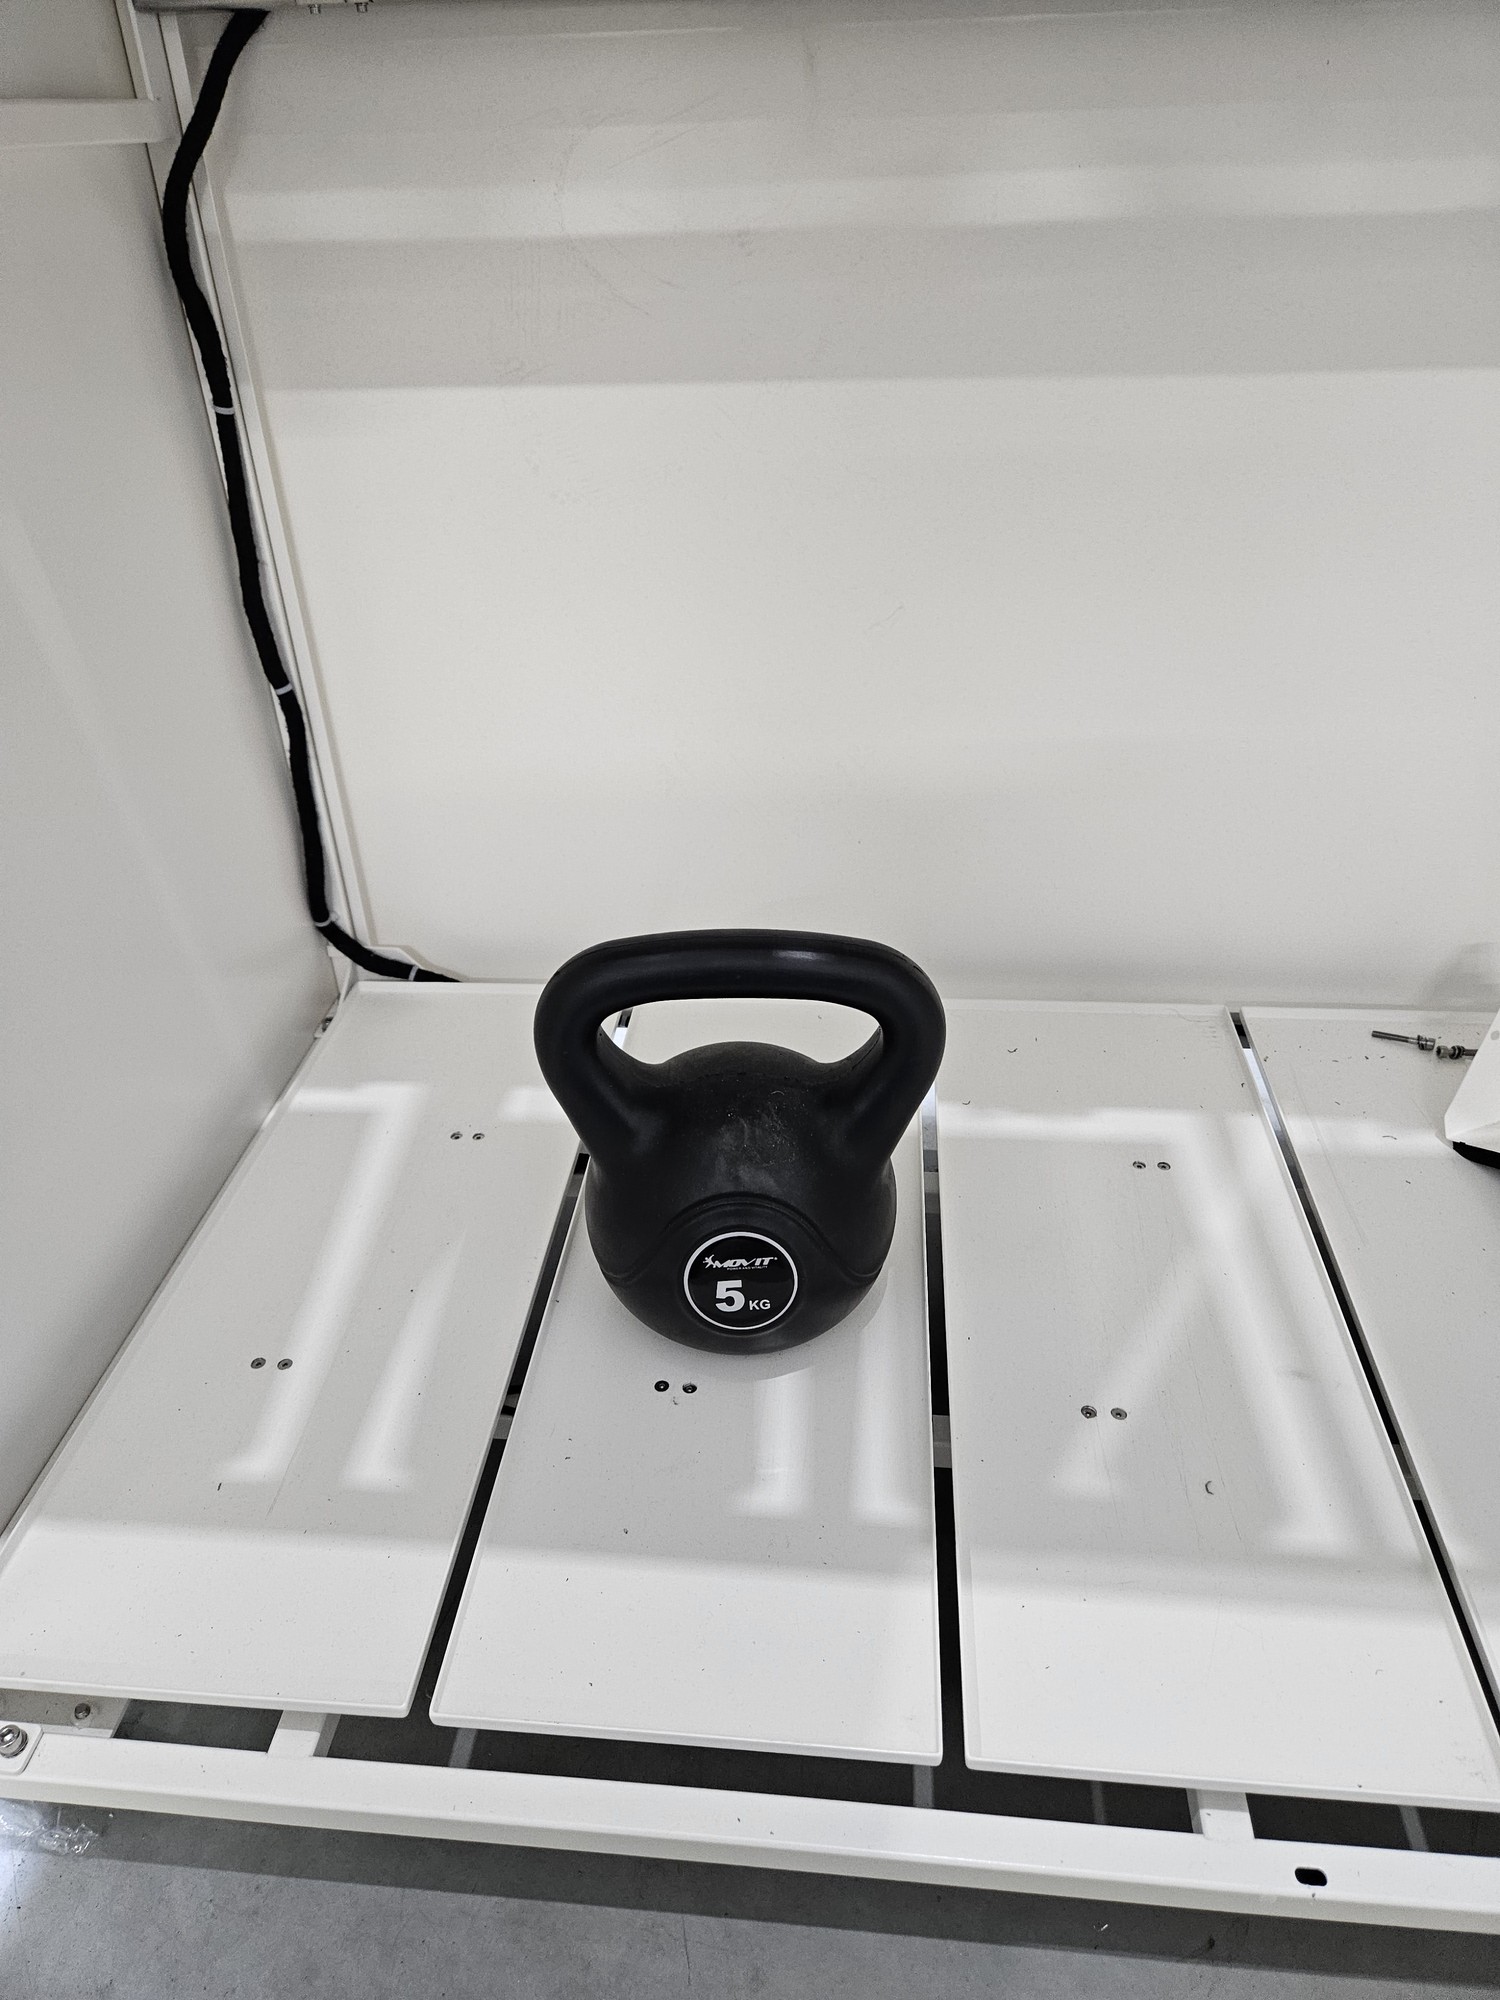
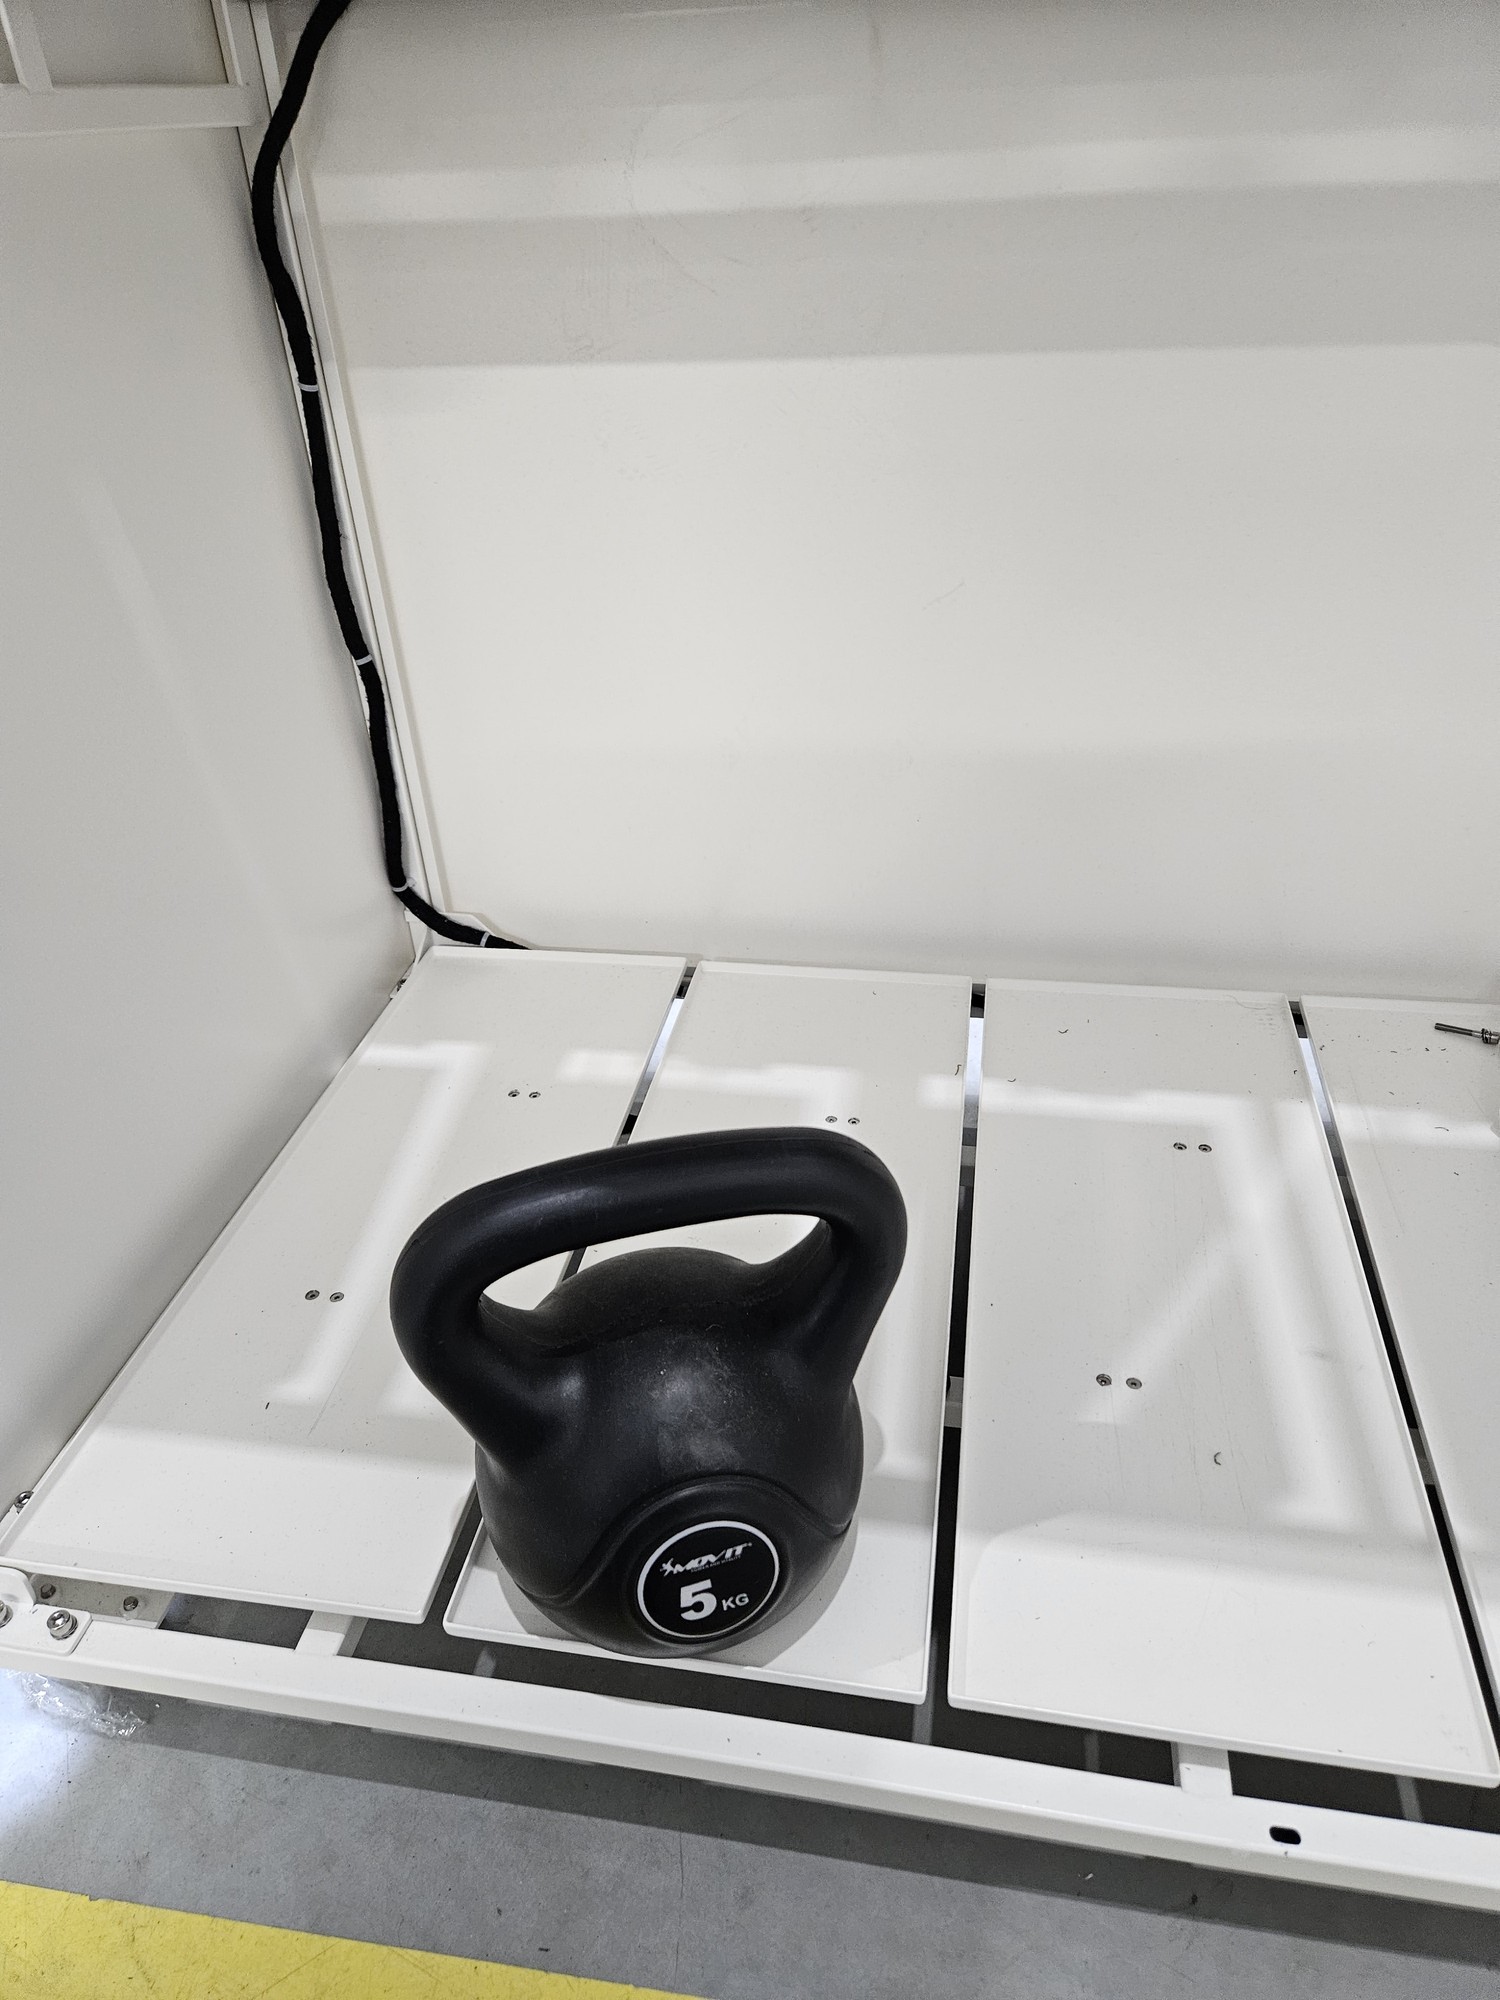
1. empty beam
2. load placed at the back
3. load placed in the middle
4. load placed at the front
 |
|
 |
|
 |
|
 |
Replace motors mechanism Smartb
|
In this document you will find a description how to replace the throw flaps motors system in the Smartb
|
You will need:
|
Before replacing disconnect device from the power supply!
With practice, some points can be omitted, but the simplest path will be described here
Step 1 Remove metal cover with shape
|
 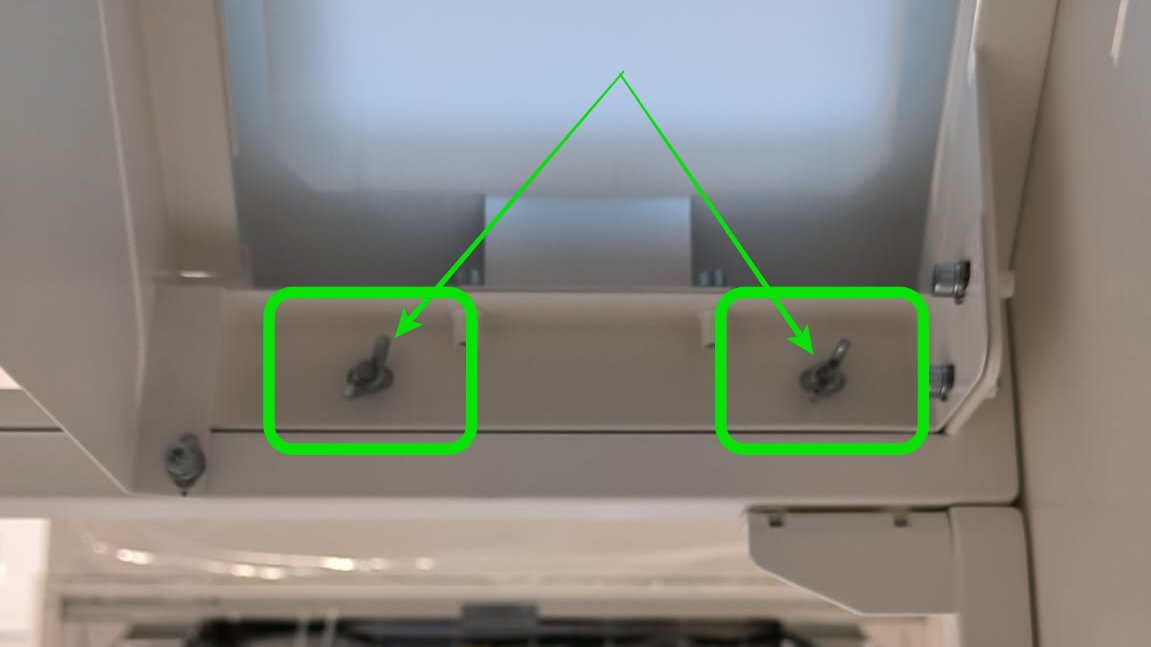 |
Step 2 Unscrew plastic flaps (optional)
|
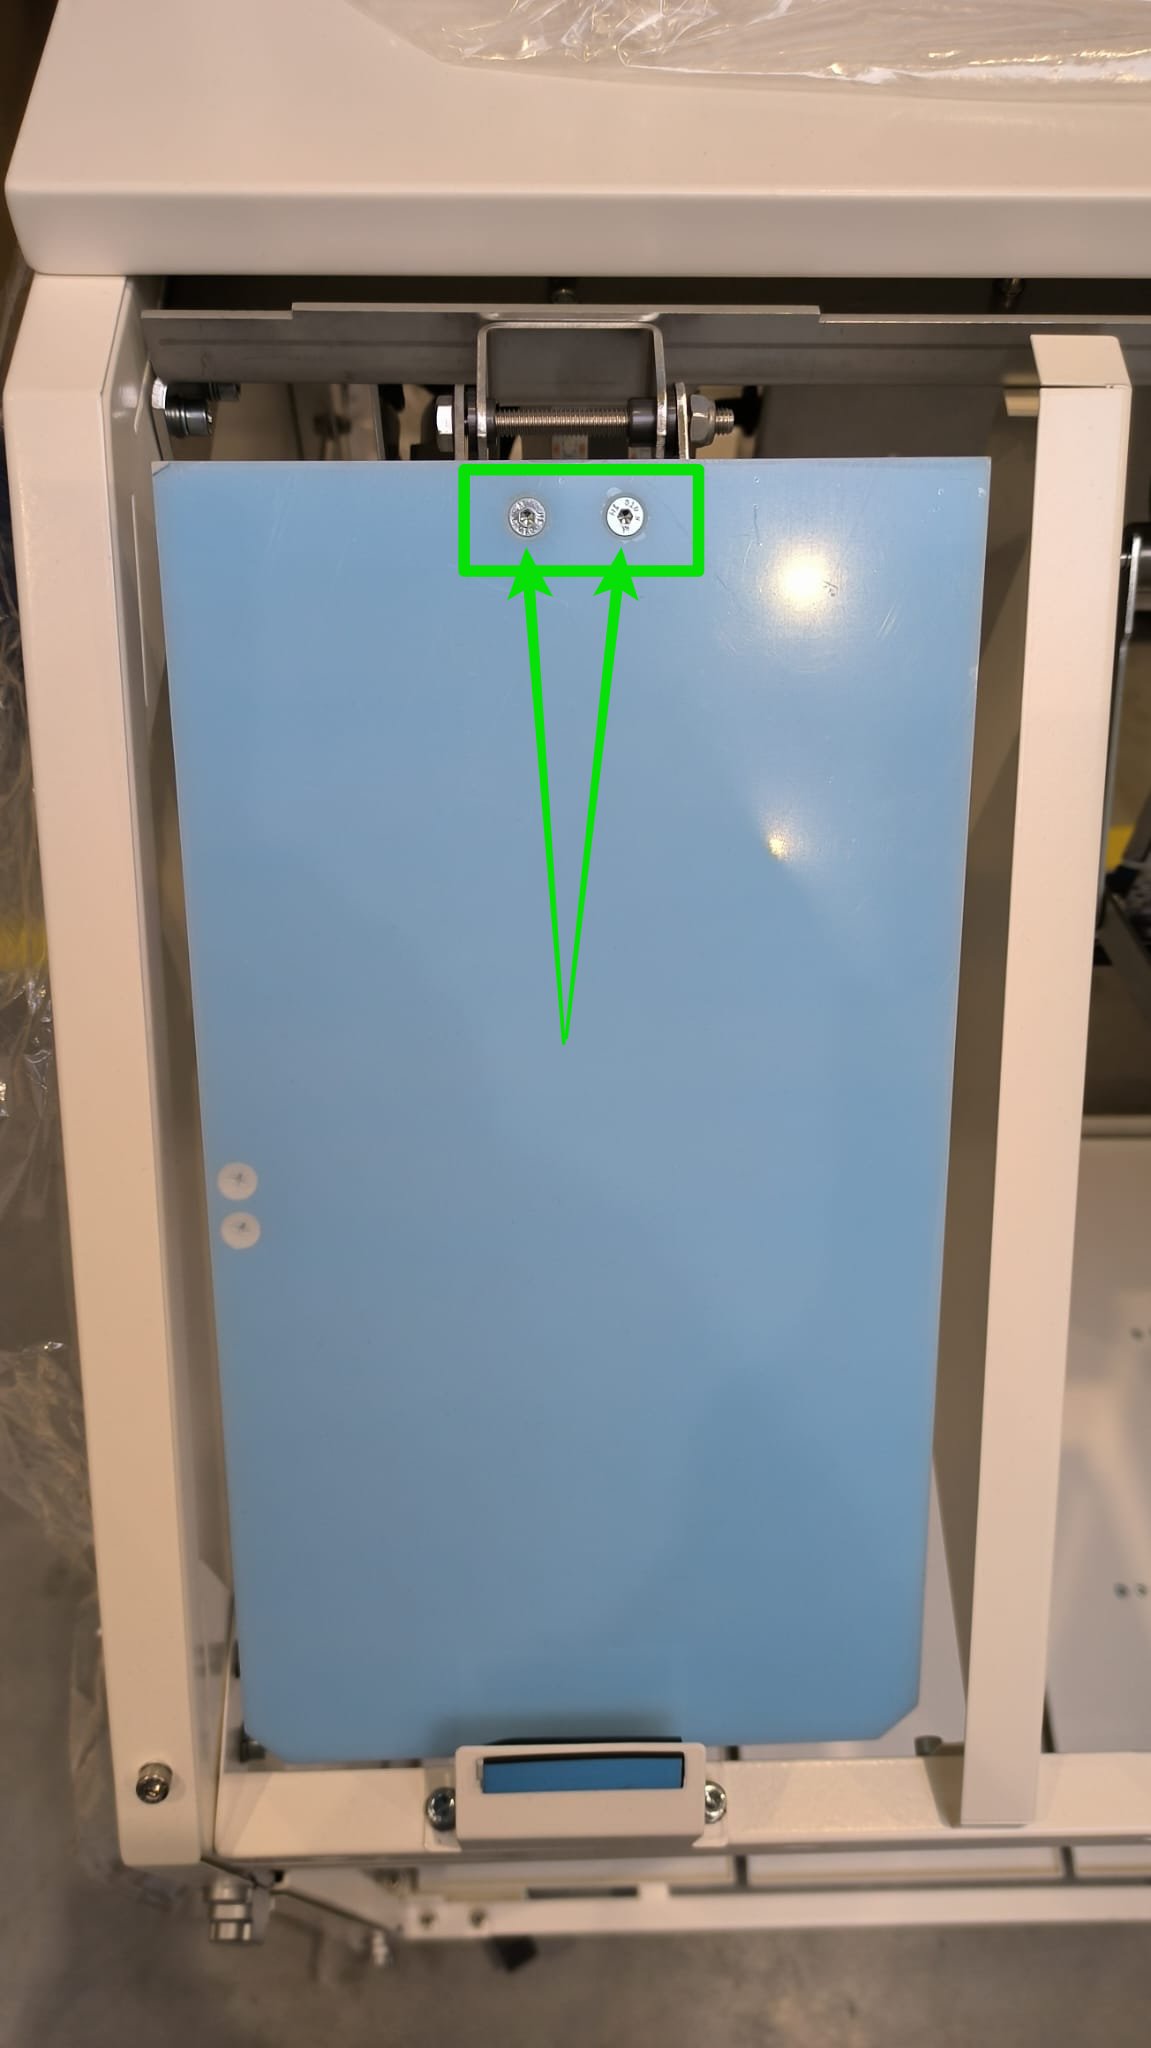  |
Step 3 Unscrew led holder (optional)
|
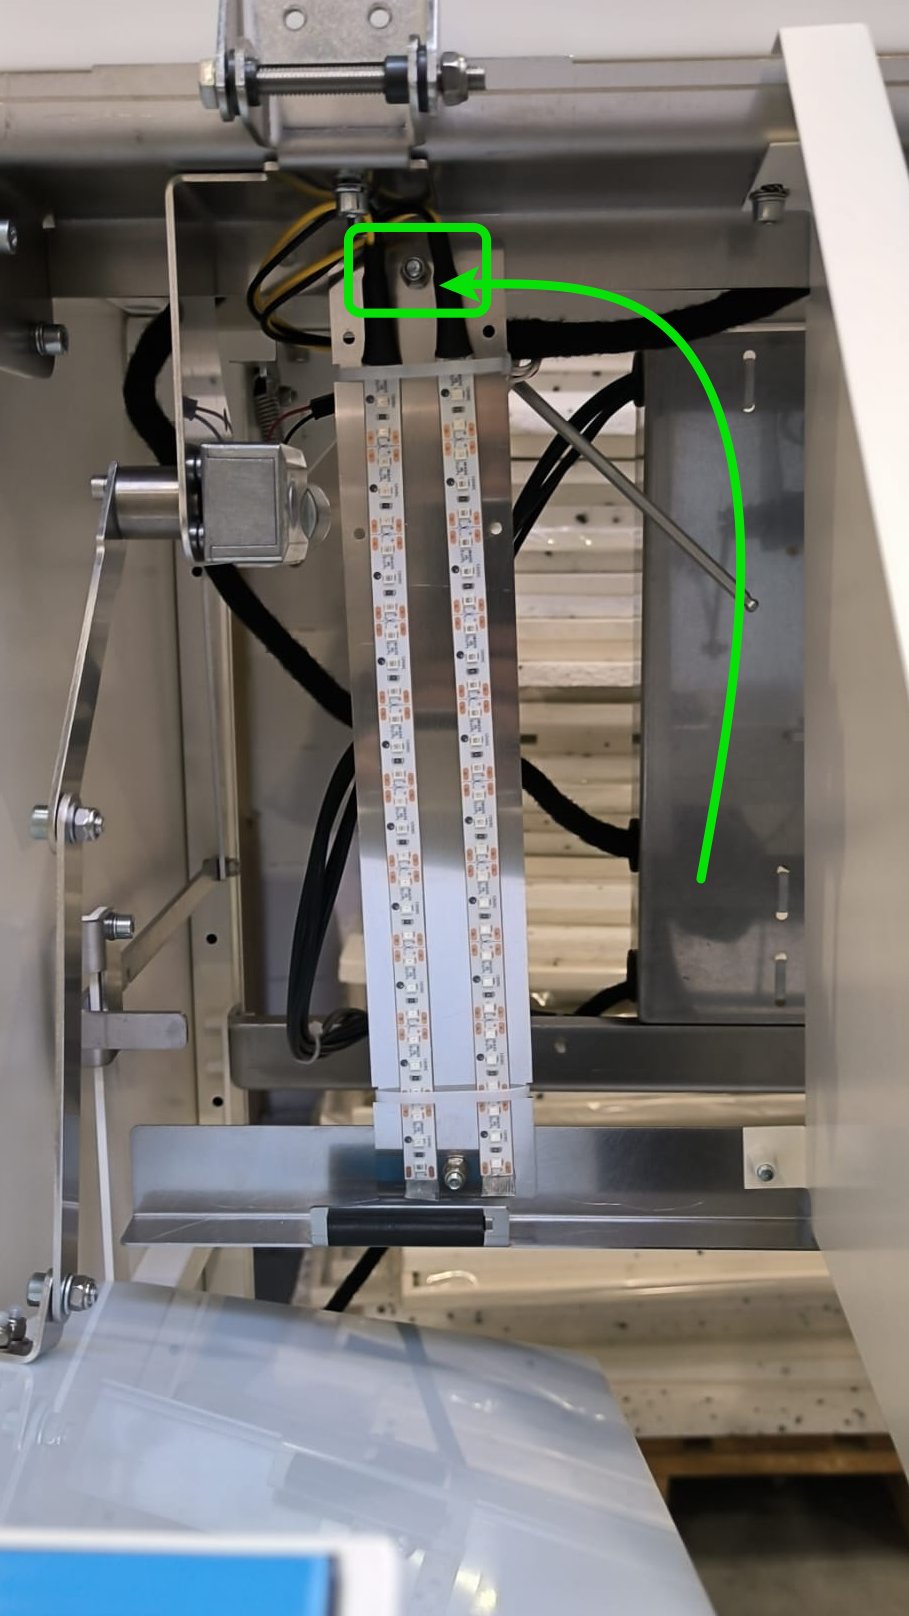 |
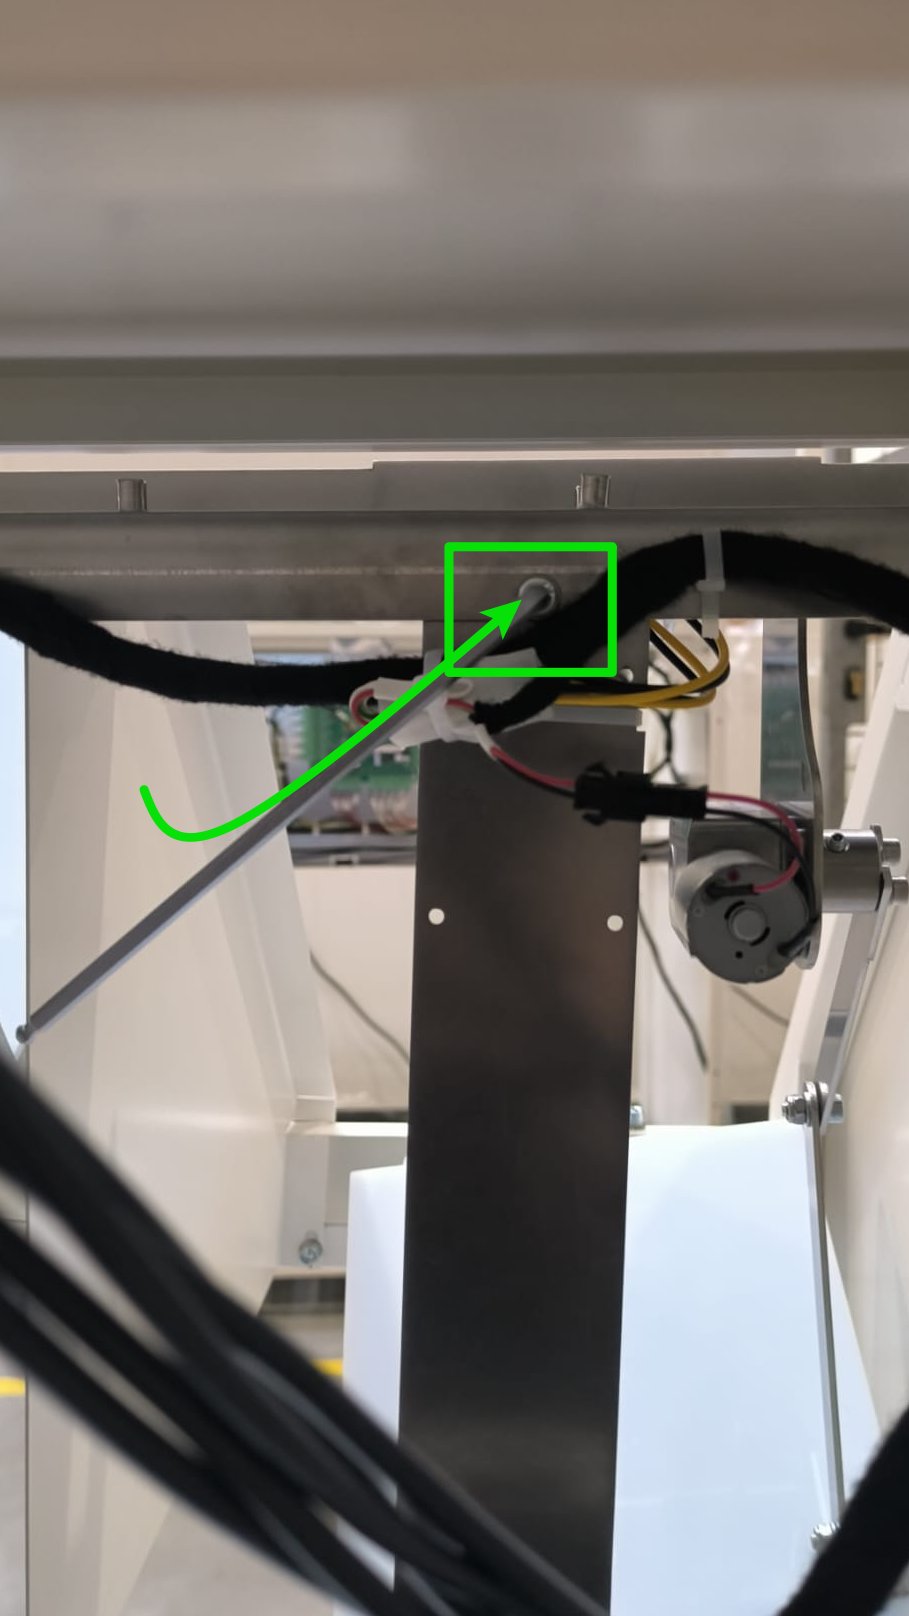 |
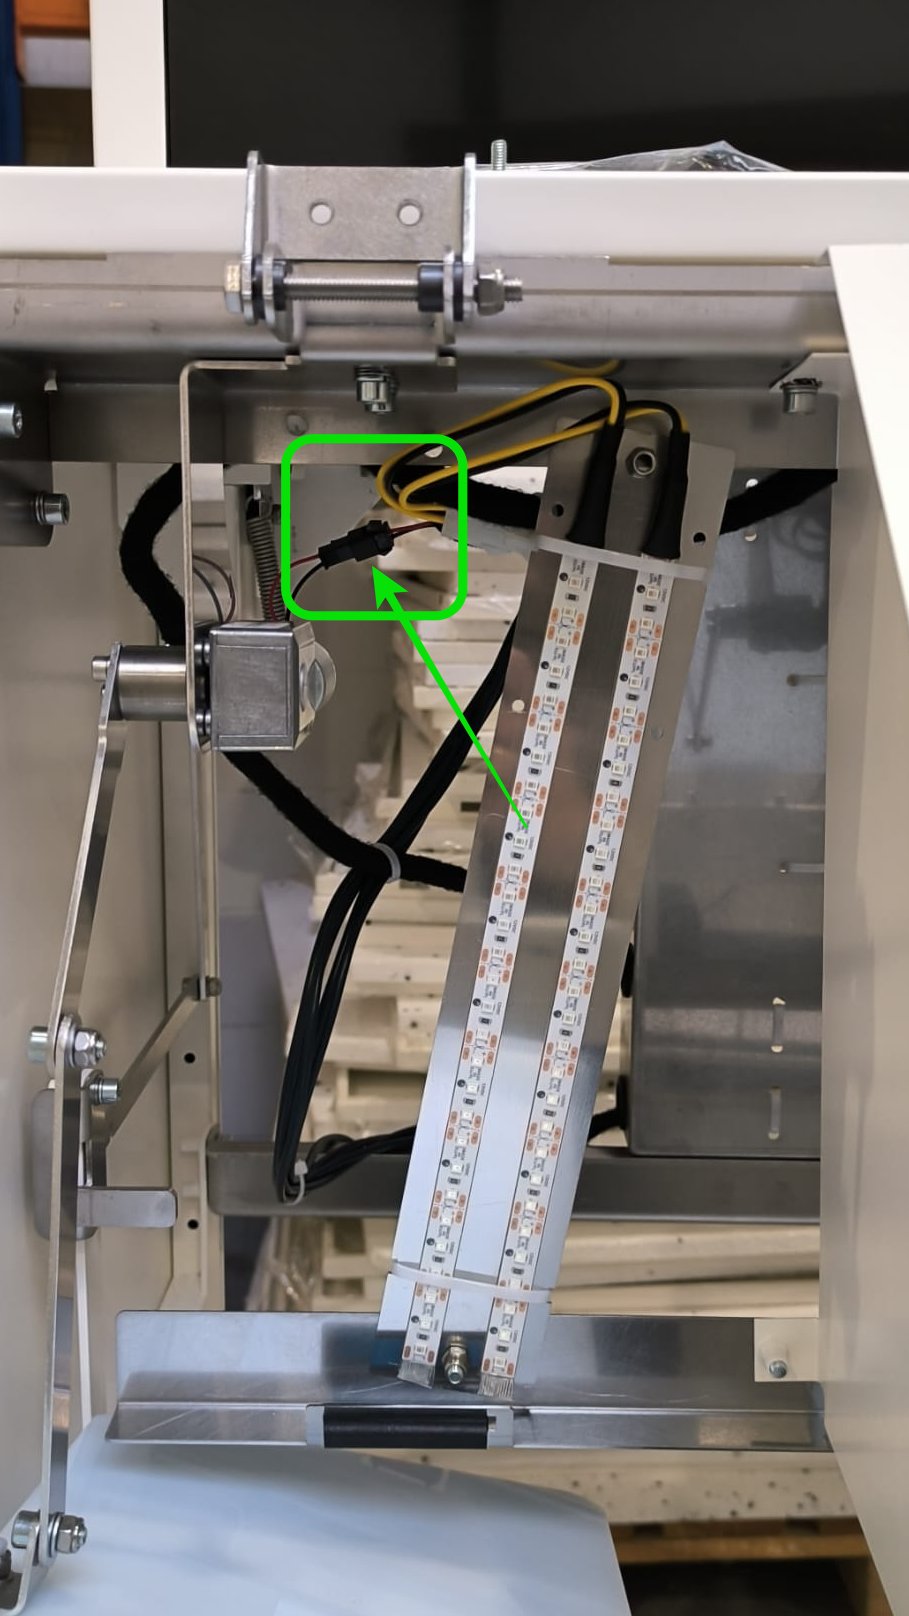
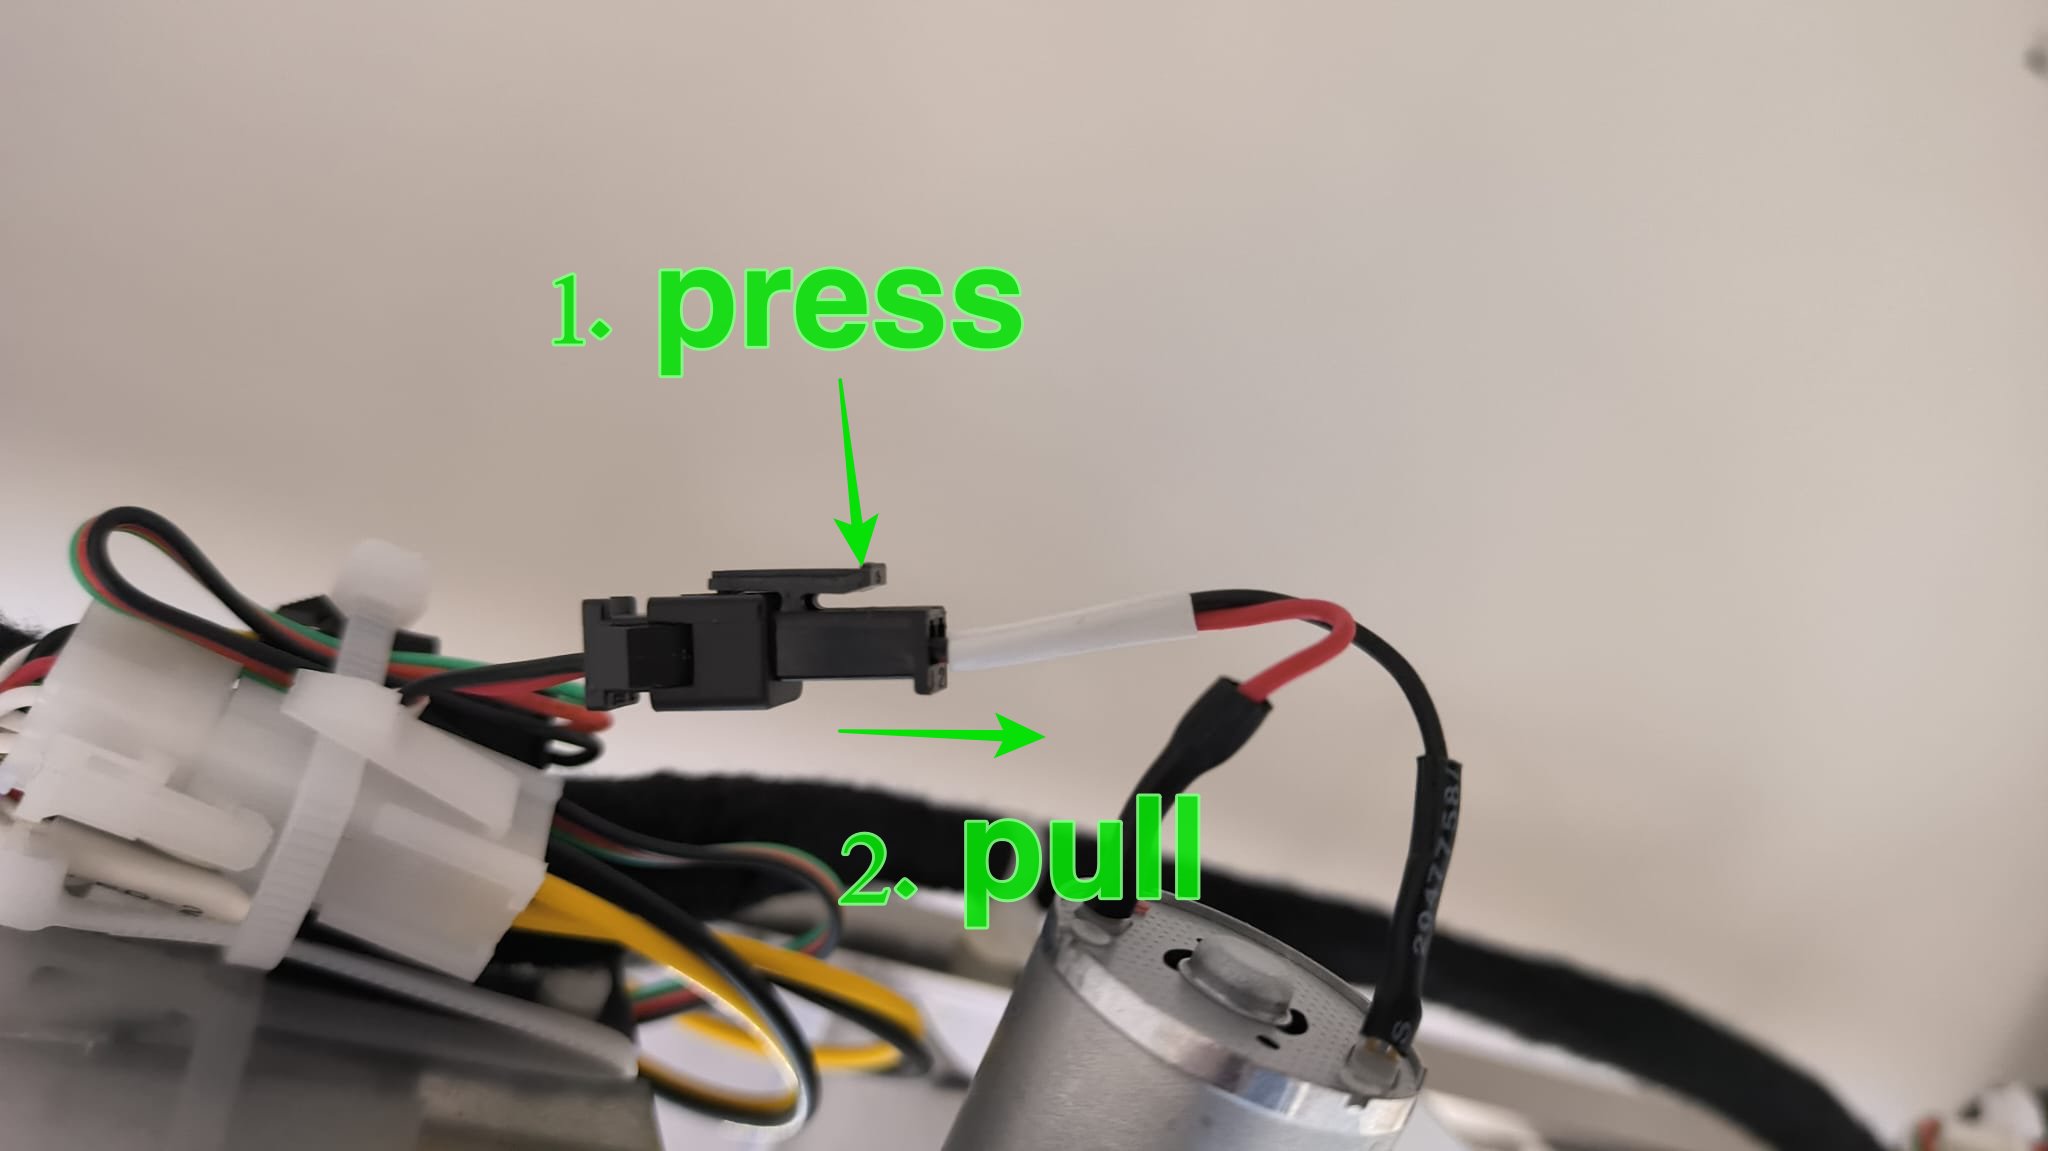
Step 4 Unplug motor cable
|
 |
|
Never pull the cables, only the plastic connector! |
|
|
|
|
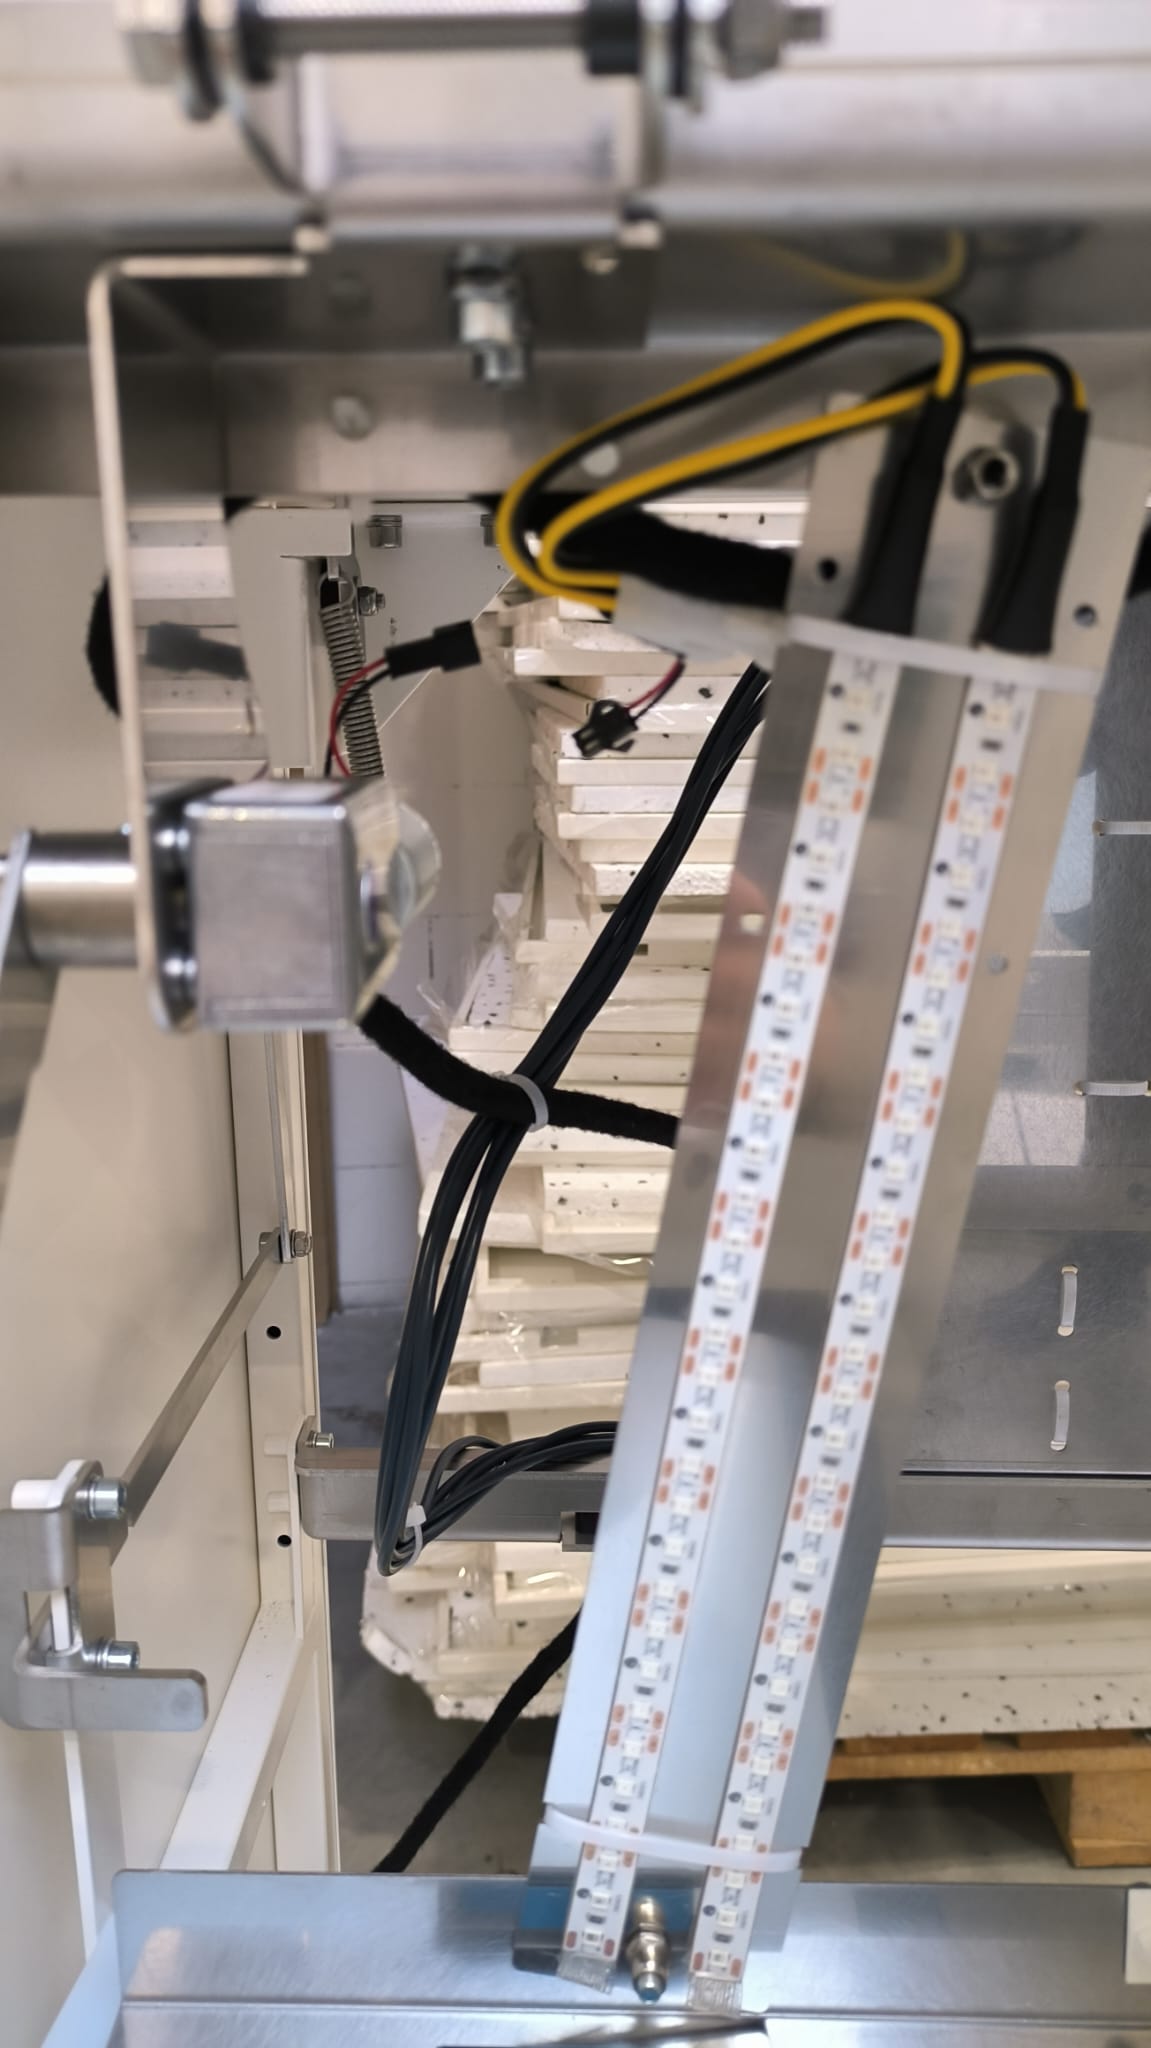
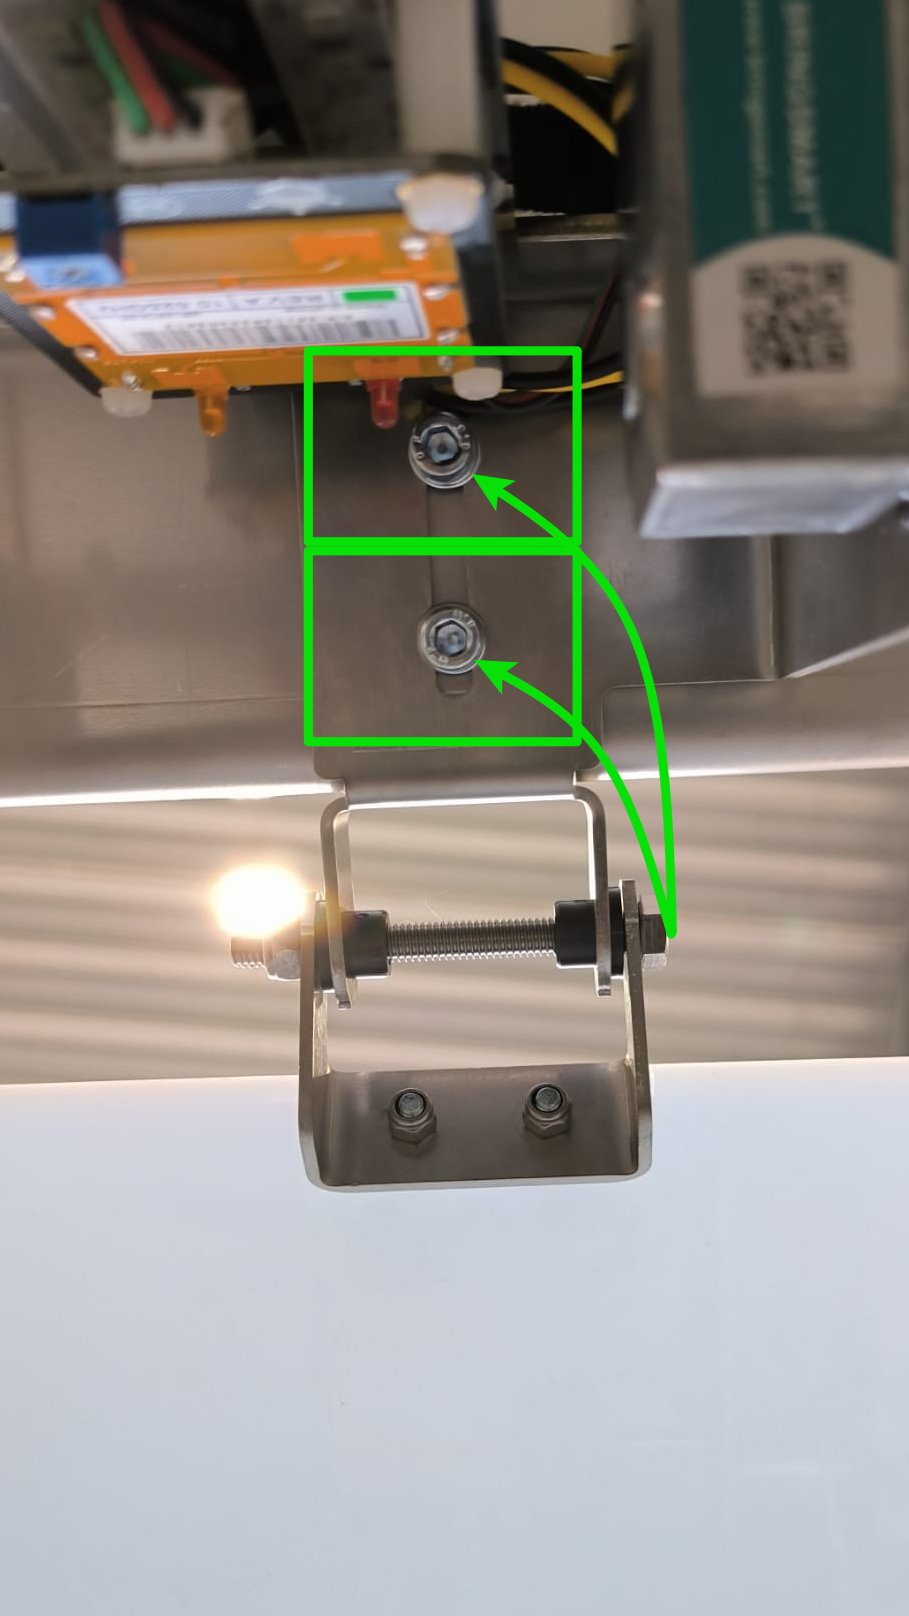
Step 5 Unscrew motor mechanism
|
 |
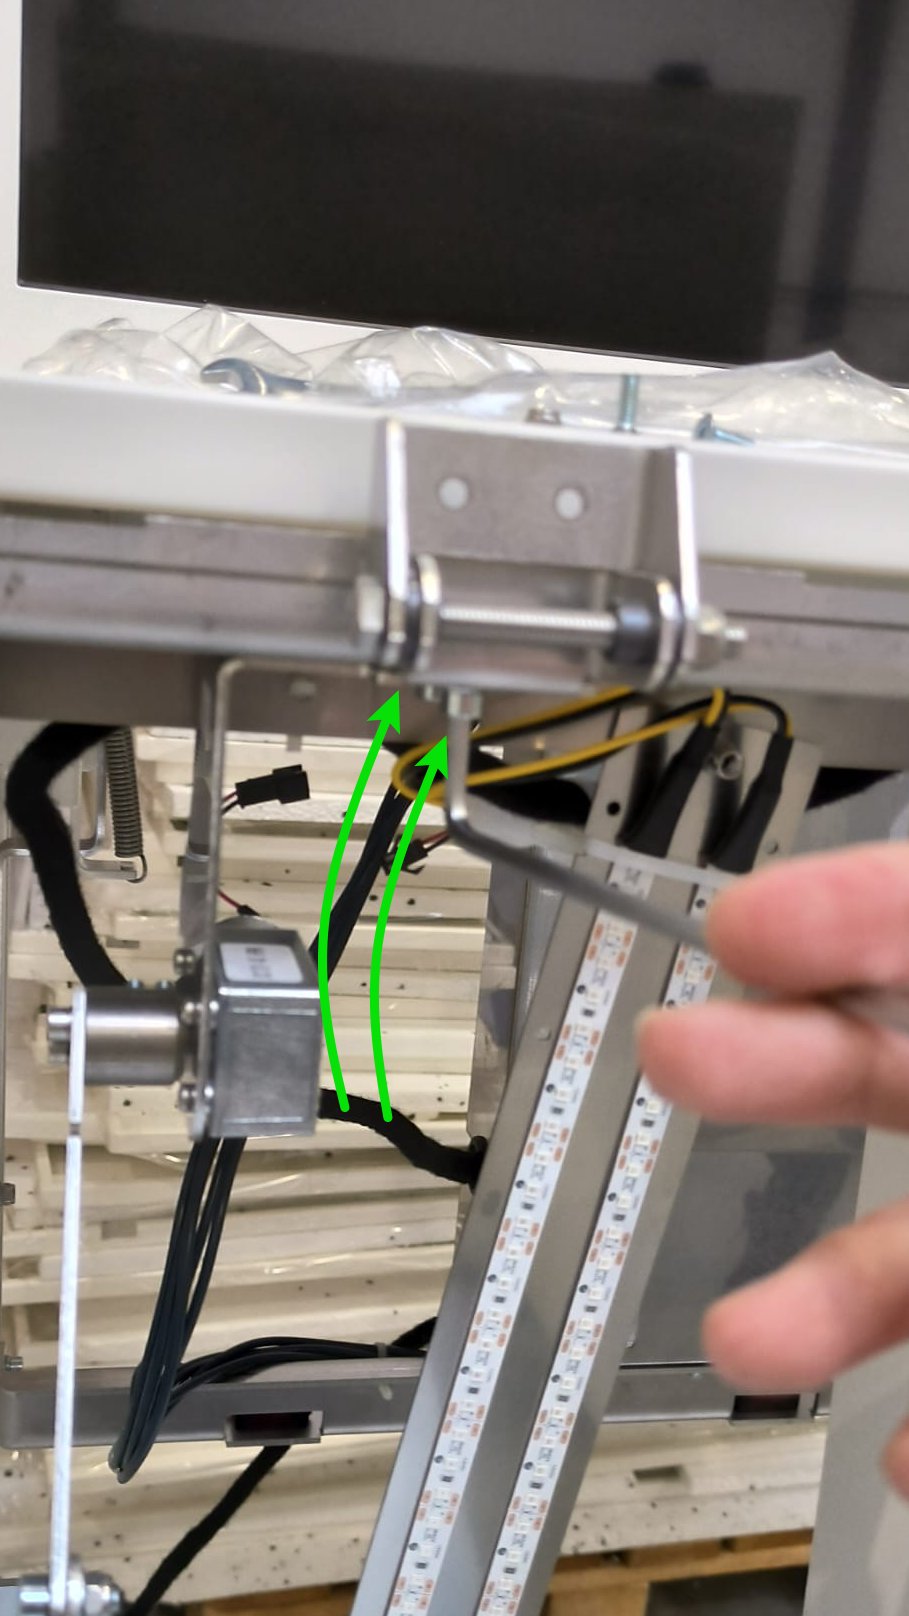 |
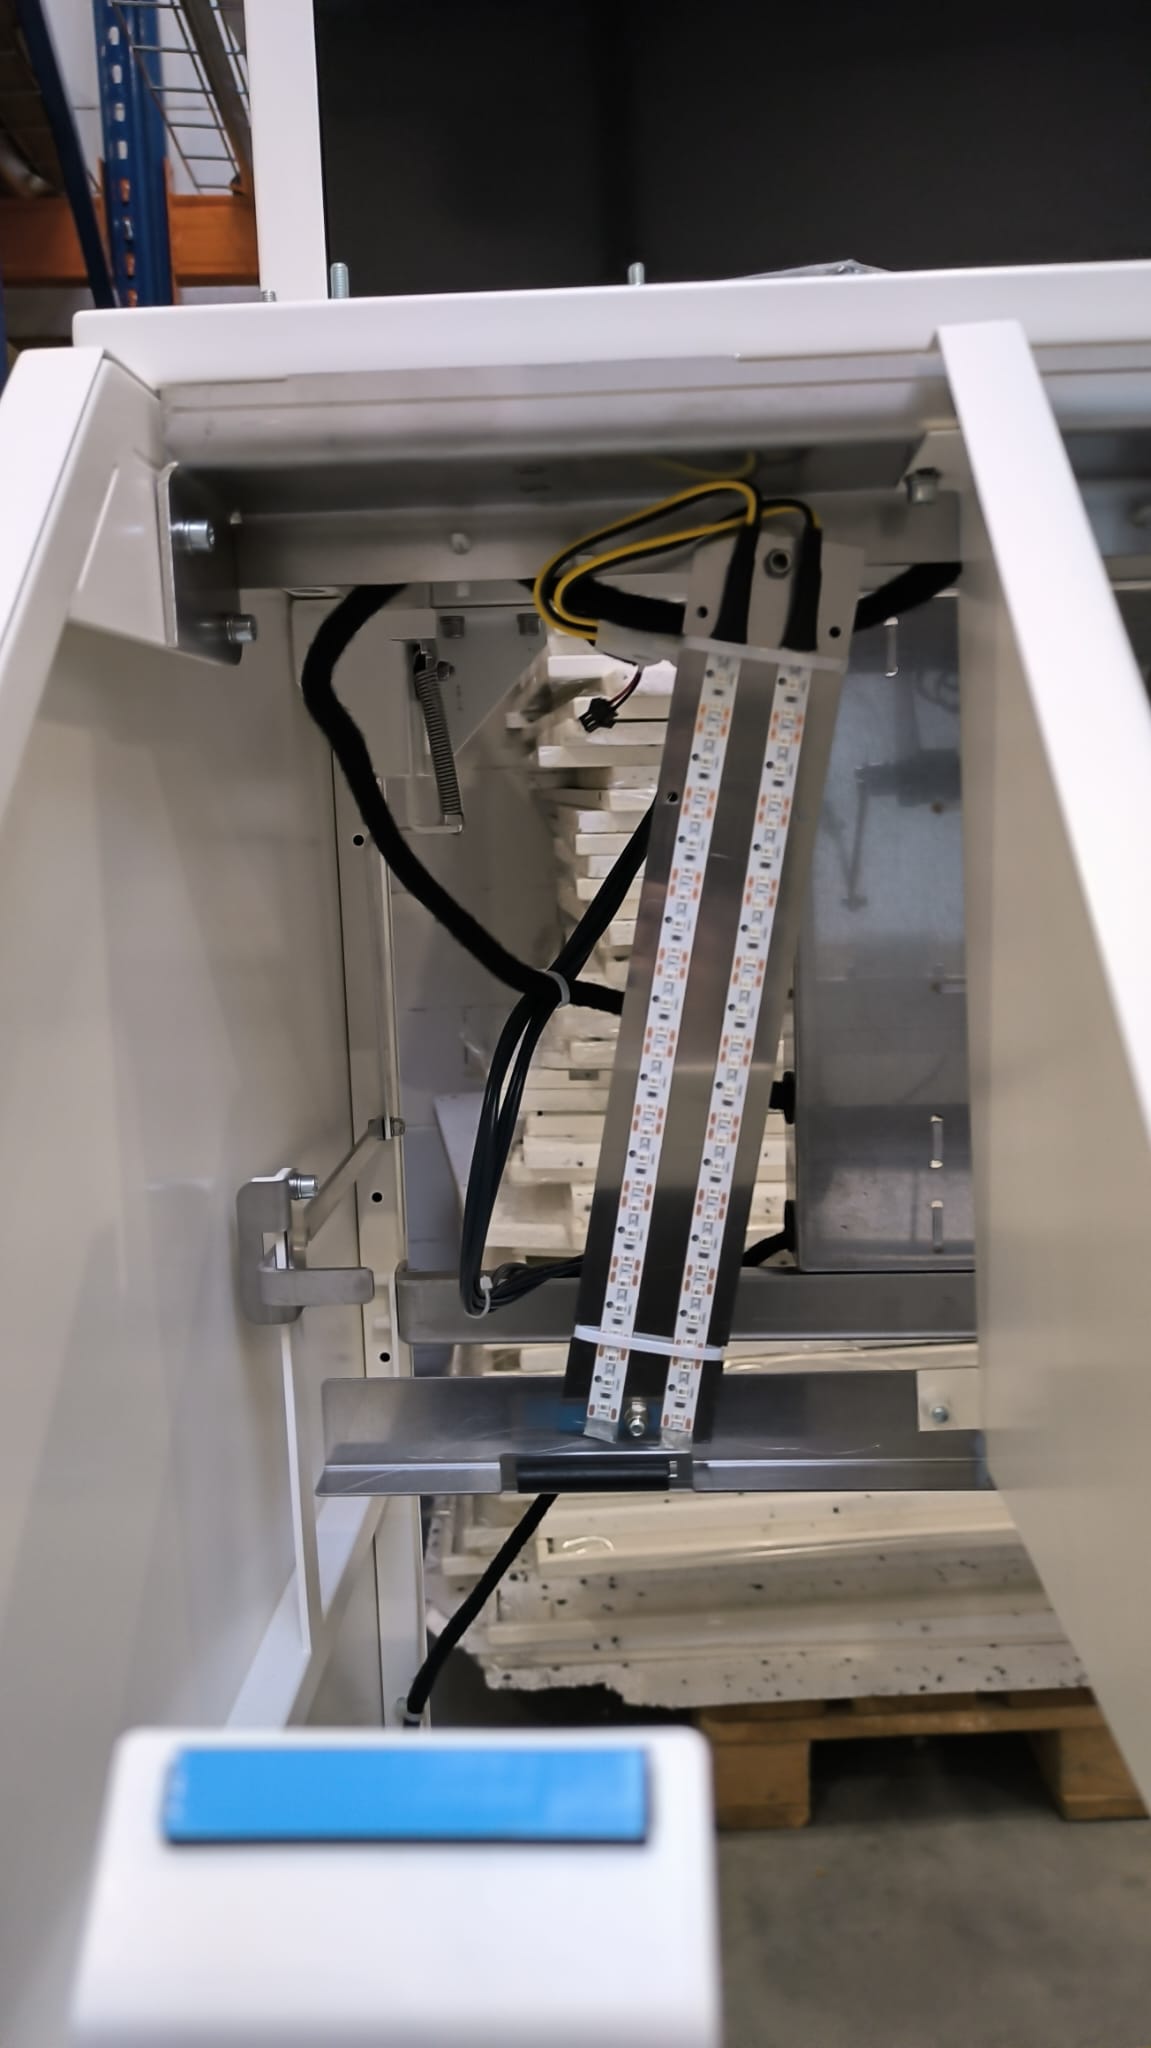
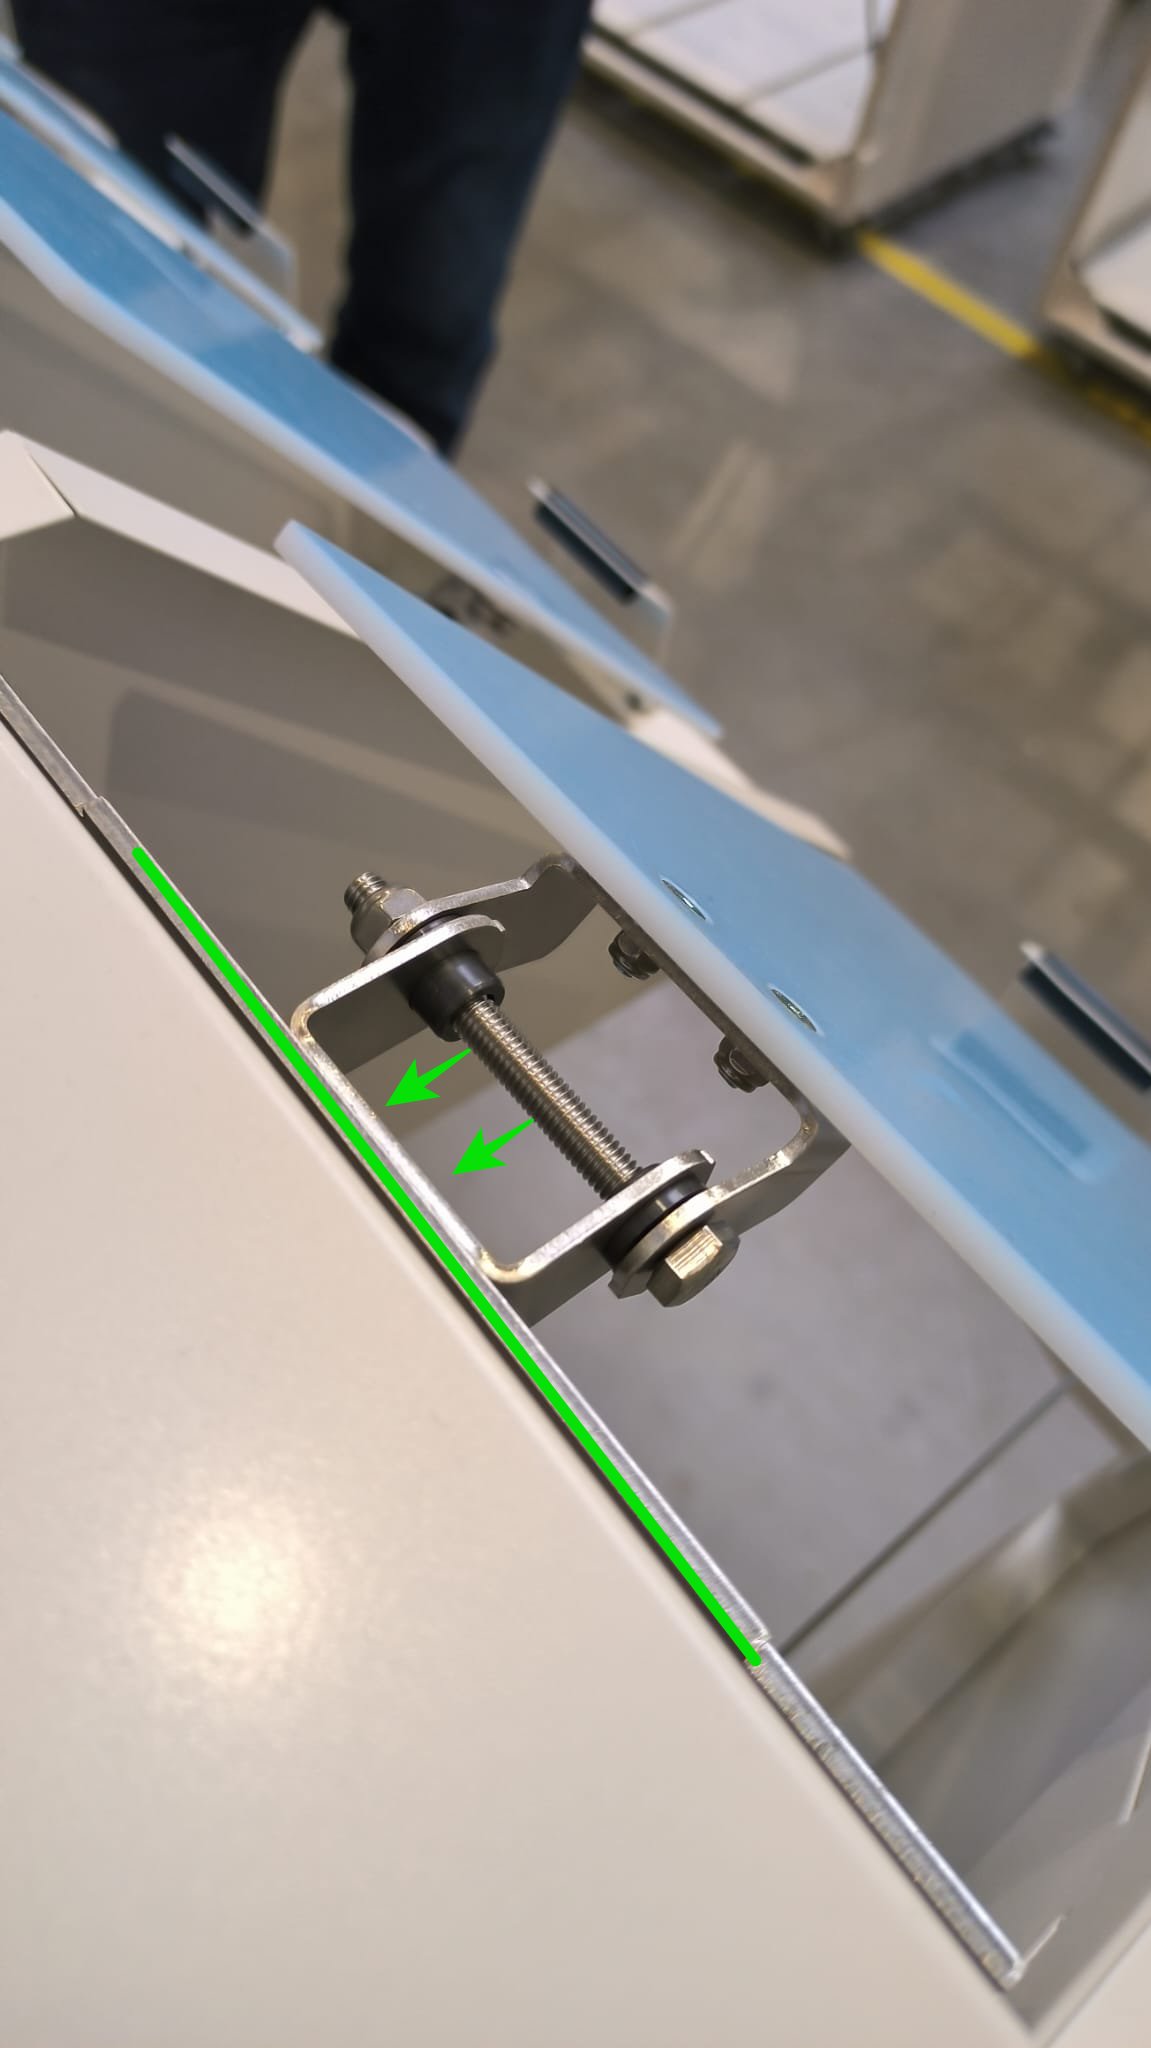
Step 6 Now you can replace with new mechanism and assembly with opposite direction of the points
|
|
 |
|
 |
Checklist after replace:
- no screws remain
- motor work properly on full range in proper direction
- LEDs works OK
- person detect system works OK (on bin 2 and 4)
Smartb motors - how it works
<Do przeredagowania i translacji>
Sterowanie silnikami w smartb bazuje na pomiarze prądu i czasach ruchu. Nie ma w tym układzie krańcówek położenia skrajnego.
Działa to tak, że logika wysterowuje ruch silnika w zadanym kierunku i czeka aż na silniku wystąpi pomiar prądu powyżej 1A (tzn, że coś blokuje dalszy ruch silnika, albo jest to odbojnik skrajny w urządzeniu albo coś innego)
Dodatkowo na początku ruchu uruchamiany jest timer który odlicza do 1s, jeżeli silnik nie osiągnie prądu powyżej 1A w czasie krótszym niż 1s to jest emitowy błąd TIMEOUT (S003). Źródłem braku prądu w czasie 1s może być awaria silnika lub silnik nie jest podłączony.
Zwykle normalny ruch silnika trwa ok. 600ms.
Jeżeli silnik osiągnie prąd 1A w czasie krótszym niż 450ms to zwykle znaczy, ze coś blokuje jego ruch. Jeżeli taki stan (osiągnięcie prądu poniżej 450ms) wystąpi 3x pod rząd to emituje błąd UNDERTIME (S002)
Po wystąpieniu błędu TIMEOUT lub UNDERTIME silnik zatrzymuje się i LED świeci się na żółto.
Co ważne, po wejściu w tryb serwisowy wszystkie silniki kasują swoją flagę o błędzie i próbują wykonać ruch ponownie wg. w/w opisu.